 Repository
 Research
zenoh plugin ros2dds · eclipse-zenoh
zenoh-plugin-ros2dds provides a Zenoh plugin and bridge for ROS 2 communication over DDS.
Standards & reference collections
Software / Research
A zenoh plug-in that allows to transparently route DDS data. This plugin can be used by DDS applications to leverage zenoh for geographical routing or for better scaling discovery. For ROS2…
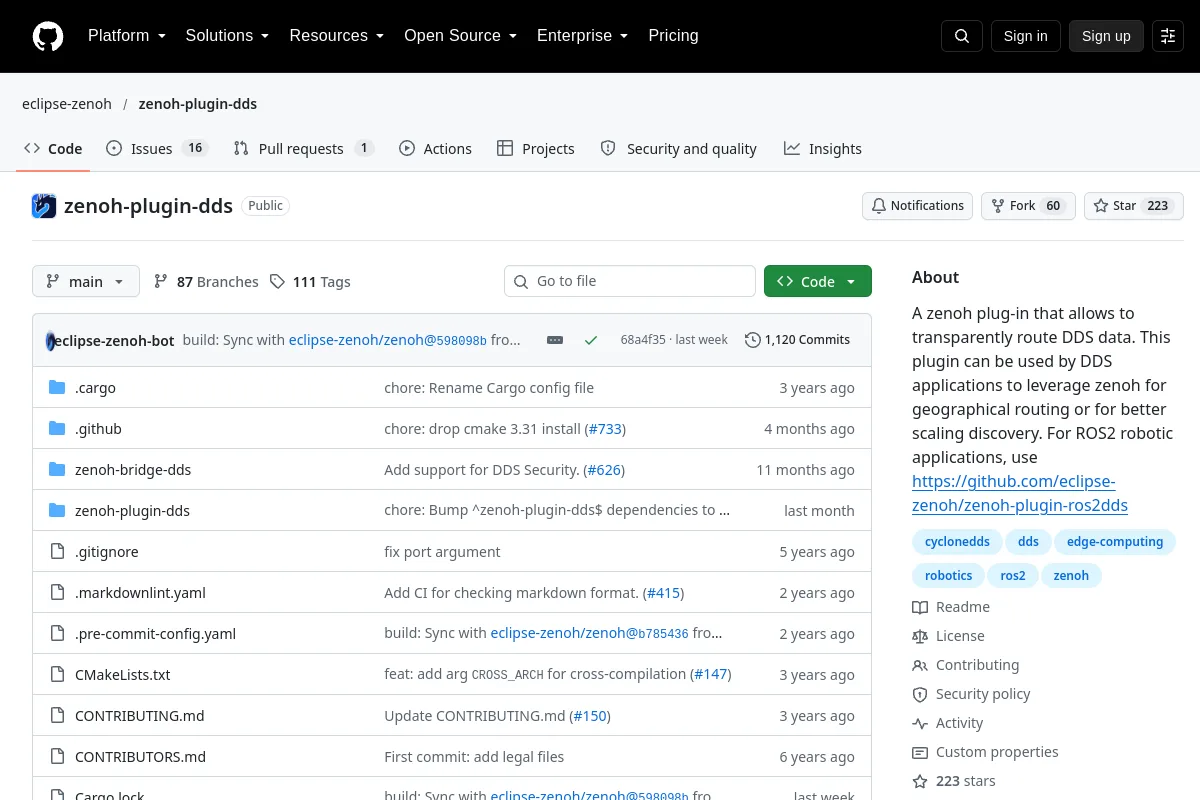
A zenoh plug-in that allows to transparently route DDS data. This plugin can be used by DDS applications to leverage zenoh for geographical routing or for better scaling discovery. For ROS2…
Publisher purpose: A zenoh plug-in that allows to transparently route DDS data. This plugin can be used by DDS applications to leverage zenoh for geographical routing or for better scaling discovery. For ROS2 robotic applications, use https://github.com/eclipse-zenoh/zenoh-plugin-ros2dds
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
zenoh-plugin-ros2dds provides a Zenoh plugin and bridge for ROS 2 communication over DDS.
Standards & reference collections