 Repository
 Research
GraspVLA · PKU-EPIC
GraspVLA provides grasping-model research pretrained with synthetic action data.
Vision-language-action
Research & learning / Research
✨ 200+ robotics papers from CoRL 2025, with TLDRs, project pages, code, and more
✨ 200+ robotics papers from CoRL 2025, with TLDRs, project pages, code, and more
Use the source to explore robotics concepts, examples and references. Source material may be historical; check the applicable version and context.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
GraspVLA provides grasping-model research pretrained with synthetic action data.
Vision-language-action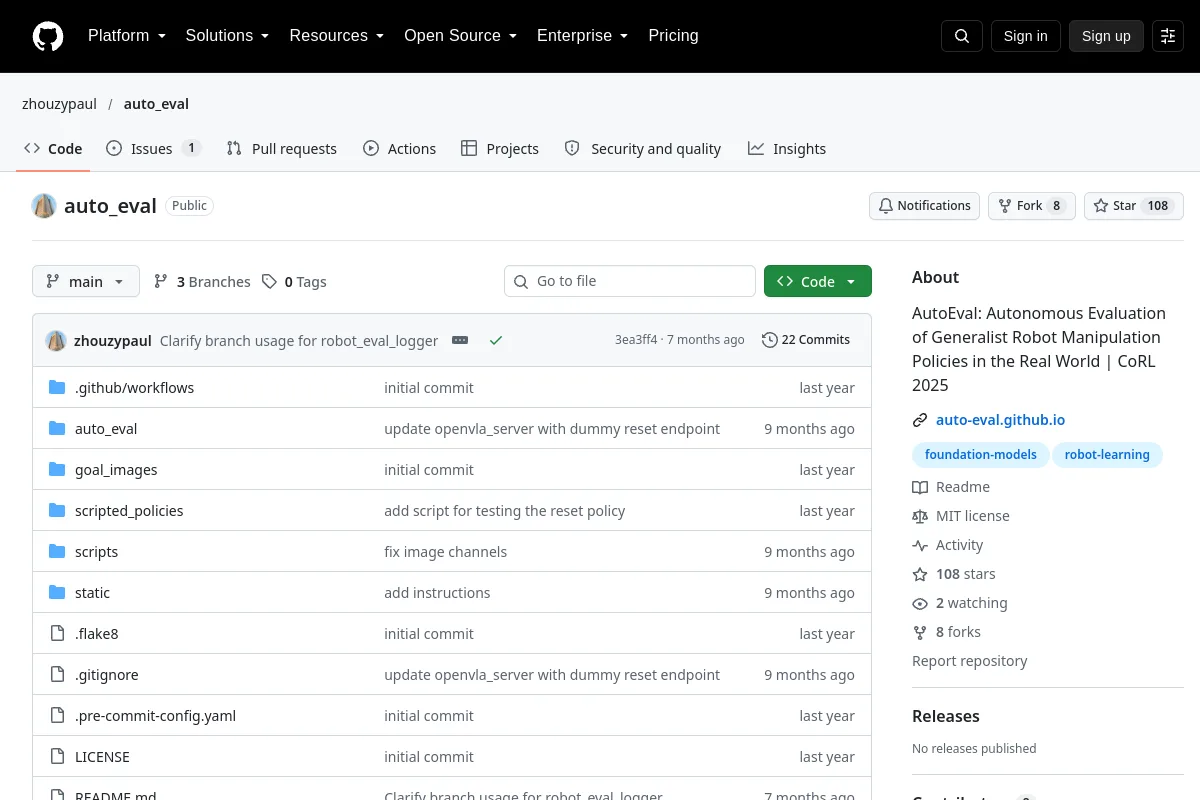 Repository
 Open source
AutoEval: Autonomous Evaluation of Generalist Robot Manipulation Policies in the Real World | CoRL 2025
Robot learning frameworks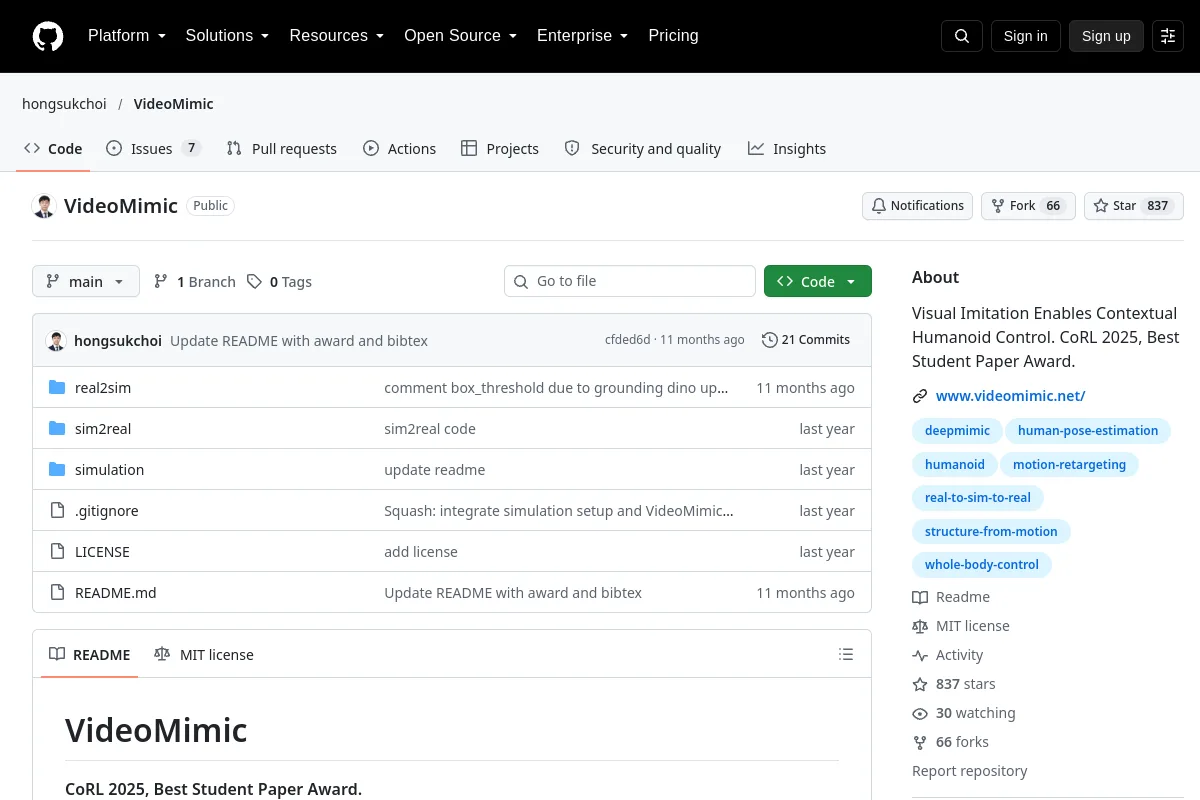 Repository
 Open source
Visual Imitation Enables Contextual Humanoid Control. CoRL 2025, Best Student Paper Award.
Robot policies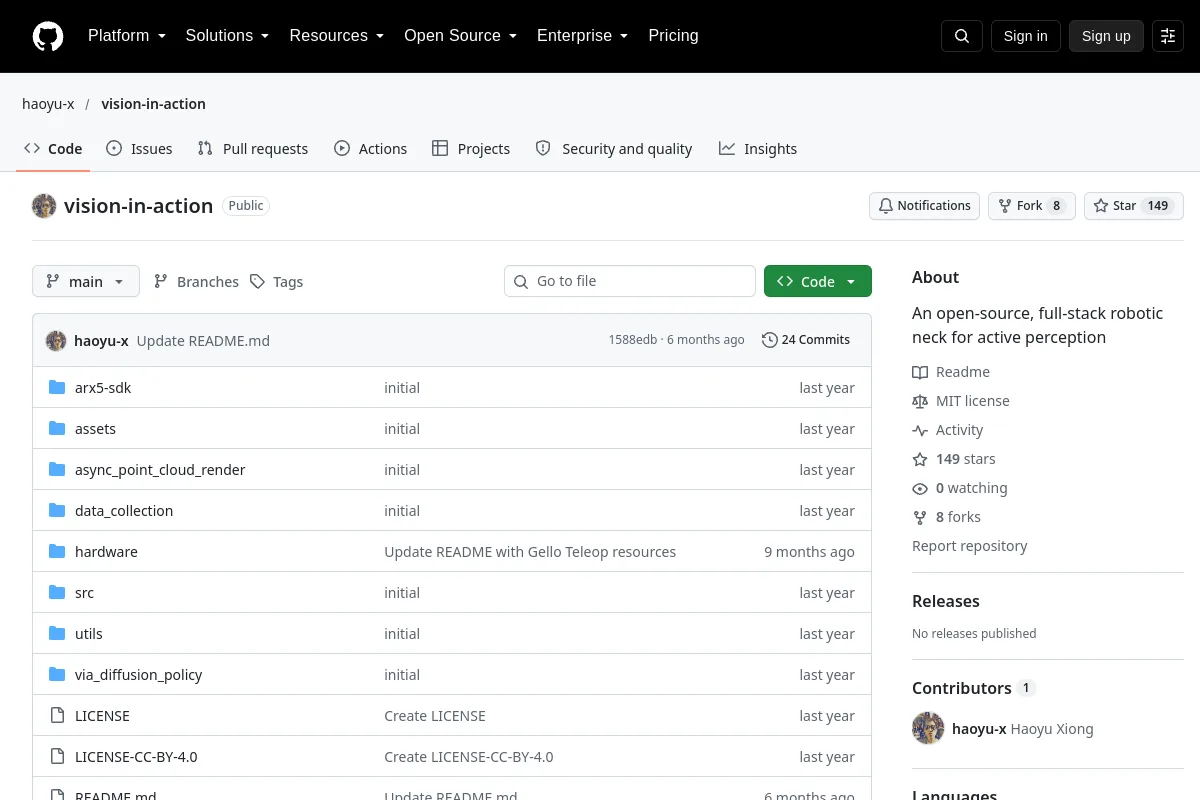 Repository
 Open source
An open-source, full-stack robotic neck for active perception
Perception & geometry