 Repository
 Open source
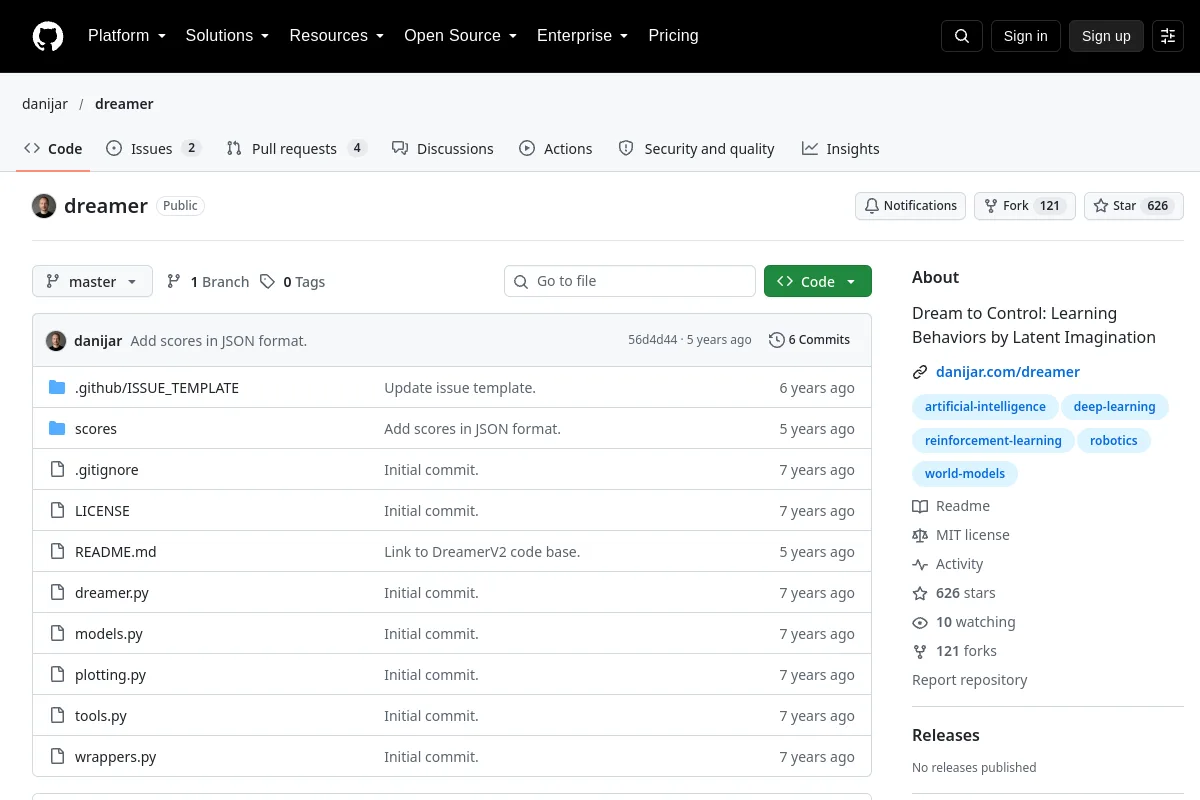
dreamer · danijar
Dreamer implementation for learning control behaviors with latent world models.
Motion planning & control
Research & learning / Open source
A curated collection of papers, explainers, and resources on World Action Models for embodied AI
A curated collection of papers, explainers, and resources on World Action Models for embodied AI
Use the source to explore robotics concepts, examples and references. Source material may be historical; check the applicable version and context.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Open source
Dreamer implementation for learning control behaviors with latent world models.
Motion planning & control Repository
 Research
Repository for our papers: Robotic World Model: A Neural Network Simulator for Robust Policy Optimization in Robotics and Uncertainty-Aware Robotic World Model Makes Offline Model-Based…
World models Repository
 Research
DayDreamer provides world-model methods for physical robot learning.
World models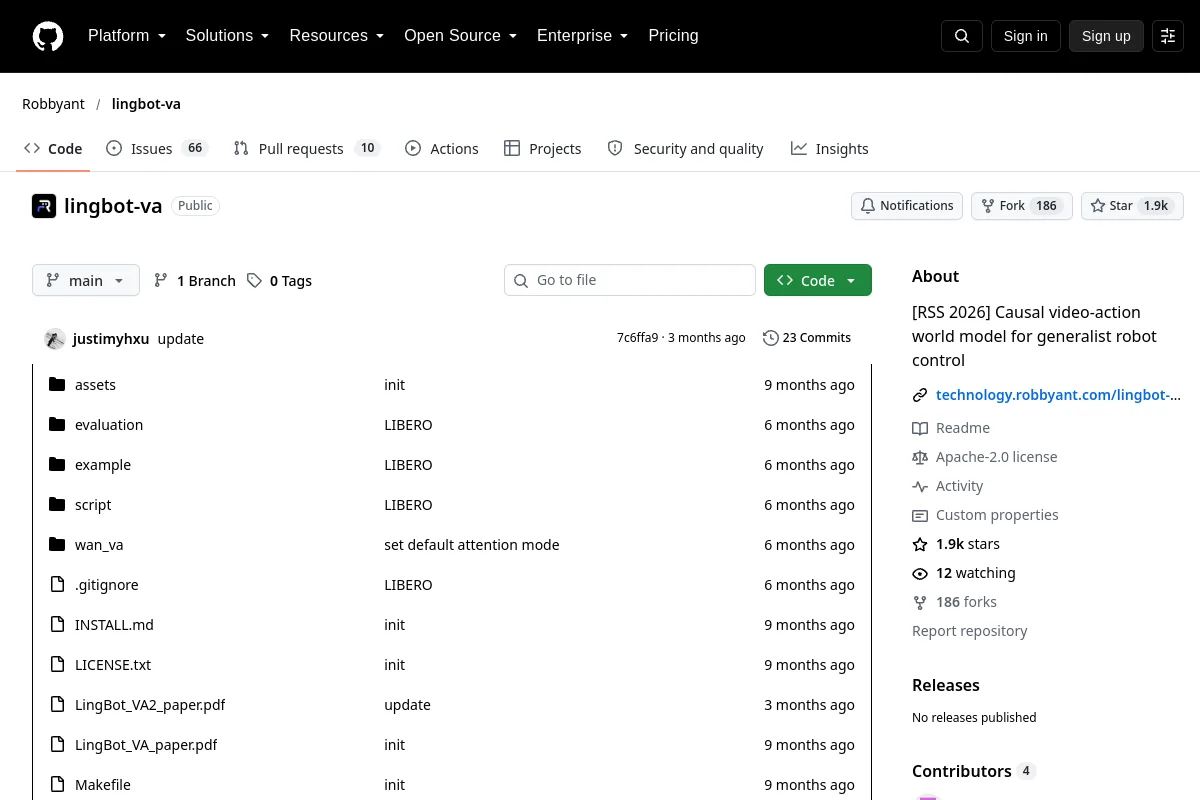 Repository
 Repository
 Research
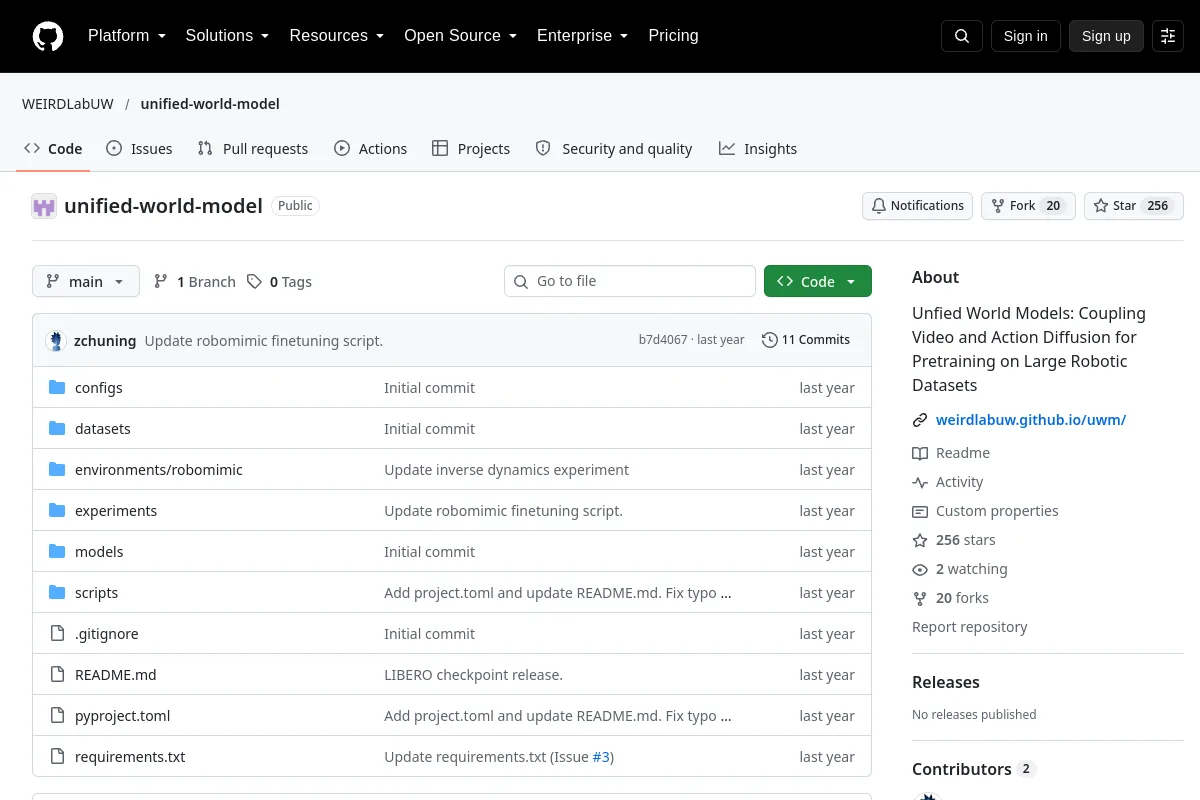
Unfied World Models: Coupling Video and Action Diffusion for Pretraining on Large Robotic Datasets
Robot demonstrations Repository
 Open source
Video-Action Models for Generalizable Robot Control Beyond VLAs
Robot learning frameworks