 Repository
 Research
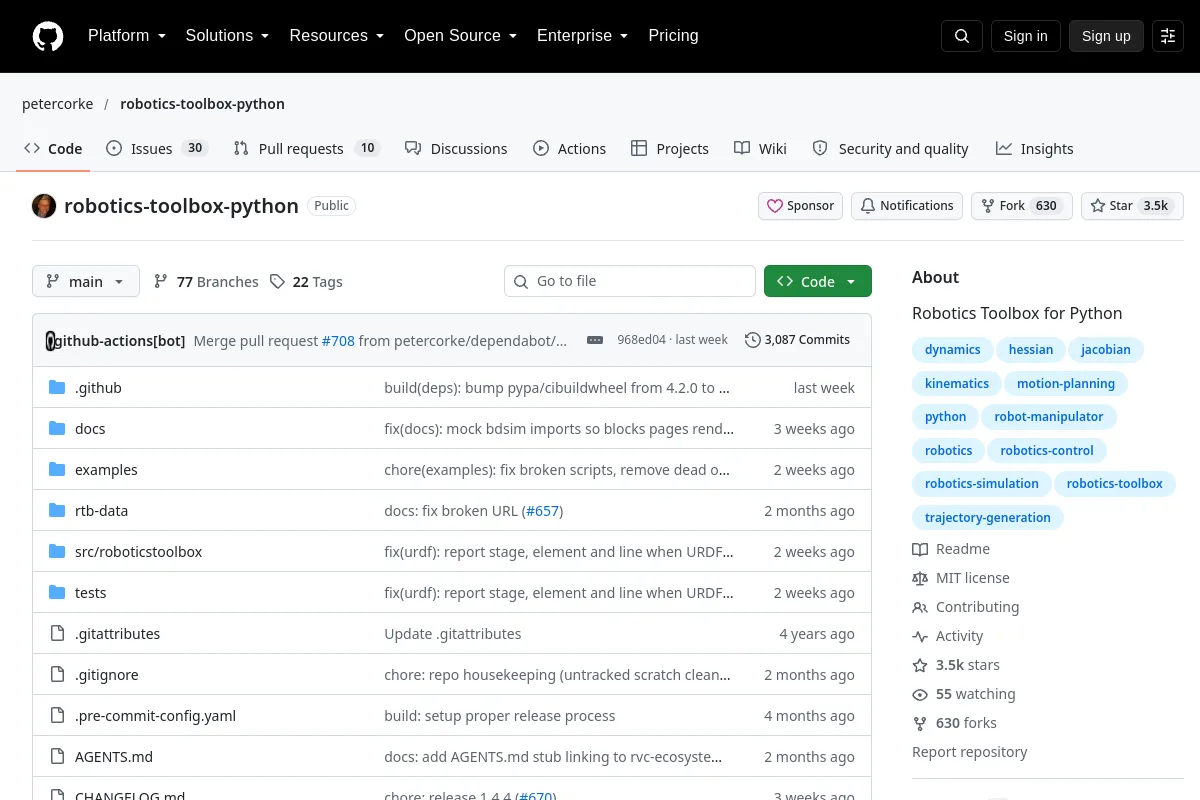
Robotics Toolbox for Python
Python tools and examples for robotics education and algorithm exploration.
Courses & documentation
Research & learning / Research
Overview about state-of-art imitation learning techniques for robotic manipulation, enabling generalization across diverse tasks and environments.
Overview about state-of-art imitation learning techniques for robotic manipulation, enabling generalization across diverse tasks and environments.
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
Python tools and examples for robotics education and algorithm exploration.
Courses & documentation Repository
 Repository
 Repository
 Open source
The English version of 14 lectures on visual SLAM.
Courses & documentation Repository
 Research
zenoh-plugin-ros2dds provides a Zenoh plugin and bridge for ROS 2 communication over DDS.
Standards & reference collections Repository
 Research
Embodied AI Lab is a research hub covering VLA, data infrastructure and robotics evaluation.
Standards & reference collections