 Repository
Editorial review pending
We are checking this resource’s relevance and classification. It is temporarily omitted from curated collections.
Generic MARL benchmarking is described without identifying a robotic or embodied environment.
Source: published project information · editorial review 9 Oct 2026. This status does not indicate a failed link check.
Benchmarks / Research
BenchMARL · facebookresearch
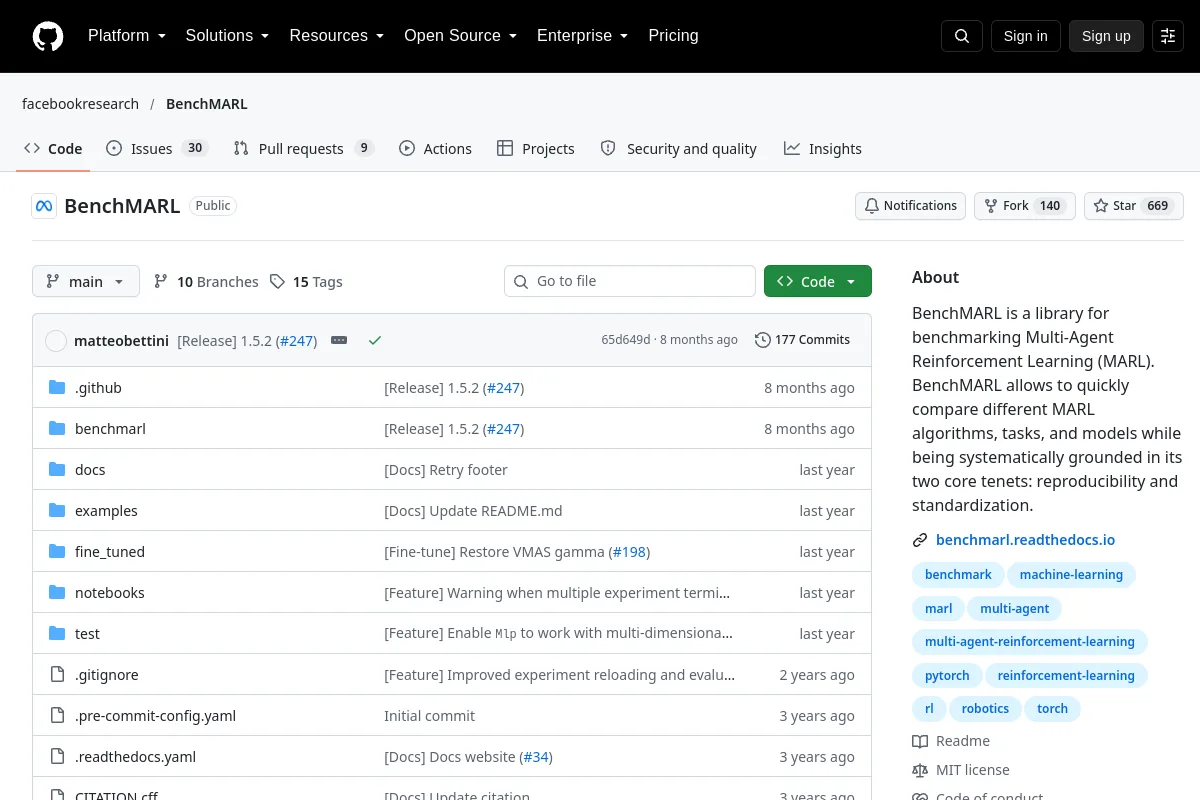
BenchMARL provides tools for comparing multi-agent reinforcement-learning algorithms, tasks and models.
Overview
BenchMARL provides tools for comparing multi-agent reinforcement-learning algorithms, tasks and models.
Publisher summary: “BenchMARL is a library for benchmarking Multi-Agent Reinforcement Learning (MARL). BenchMARL allows to quickly compare different MARL algorithms, tasks, and models while being systematically…”
Use its repository to inspect the implementation, documentation and supported workflows. This directory record identifies the maintainer, code license and related resources; it does not claim that the project has been installed or tested on your robot.
Project information
- Maintainer
- facebookresearch
- Primary language
- Python
- Repository code license
- MIT
- Model-weight license
- Not recorded
- Dataset license
- Not recorded
- Hardware design license
- Not recorded
- Maintenance
- Not archived in the last recorded metadata
- Last observed repository push
- 2026-02-07
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
- BenchMARL
- What is BenchMARL 🧐?
- Why would I BenchMARL 🤔?
- Table of contents
- How to use
- Notebooks
Browse this resource’s categories
Explore related collections
Browse Benchmarks →More in Benchmarks
Repository
 Repository
 Repository
 Repository
 Repository
 Research
actionshift · Archerkattri
ActionShift evaluates adaptation to hidden robot action-interface contracts on ManiSkill tasks.
Manipulation Repository
 Research
RMBench · RoboTwin-Platform
Memory-Dependent Manipulation Benchmark based on RoboTwin
Manipulation