A robot arm can pull on a load, but the tug doesn’t stop at its shoulder. ETH Zurich researchers Lukas Molnar and colleagues tested a physical Unitree B2 quadruped fitted with a Z1 arm in a controlled indoor setup. It walked while pulling a 10 kg load through an indoor rope-and-pulley rig. The first arXiv preprint appeared November 24, 2025. The exact day and room of the test were not disclosed.
Because the pull can disturb the body while it walks, the team used one controller to work out how the legs and arm should move together.
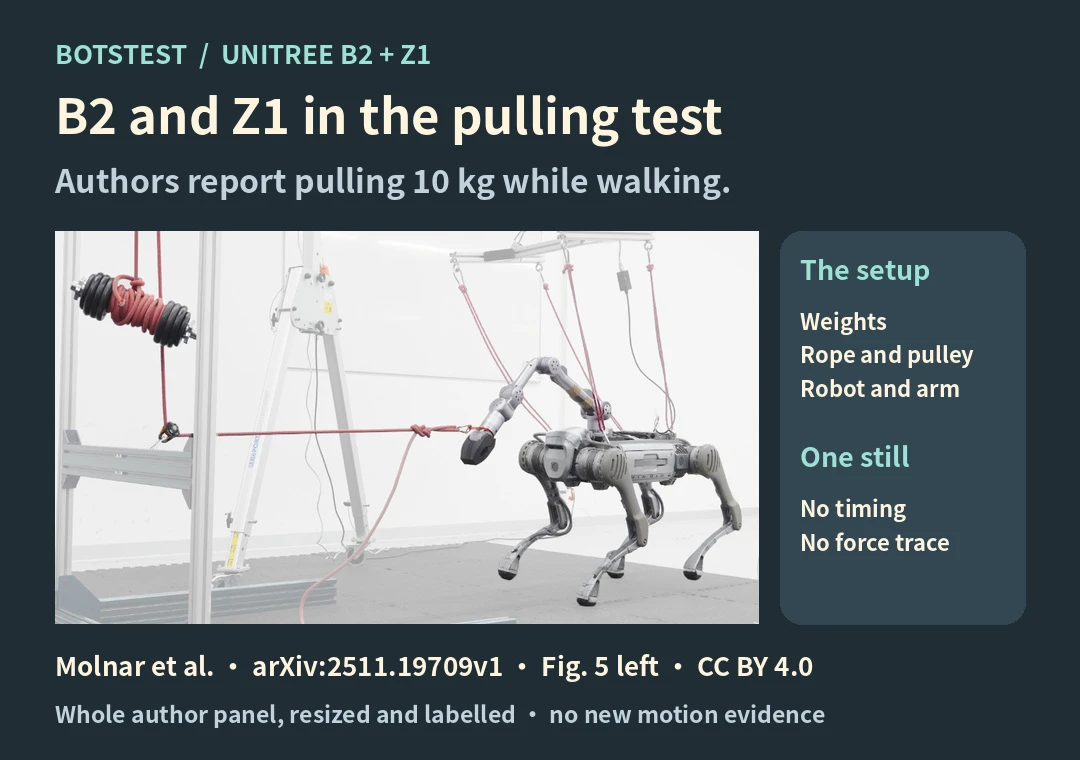
Authors’ hardware demonstration, Figure 5 left panel in full: the line runs from the gripper through a pulley fixture to suspended weights.
One plan for the legs and arm
The arm pulls; the feet have to deal with the reaction. Instead of asking the arm and legs to work independently, the controller starts from the robot’s estimated state and plans joint torques for both. It repeats the calculation as the robot moves. The authors report that this particular controller ran off the robot at 80 Hz and sent commands over Ethernet. That is a controller update rate, not speed.
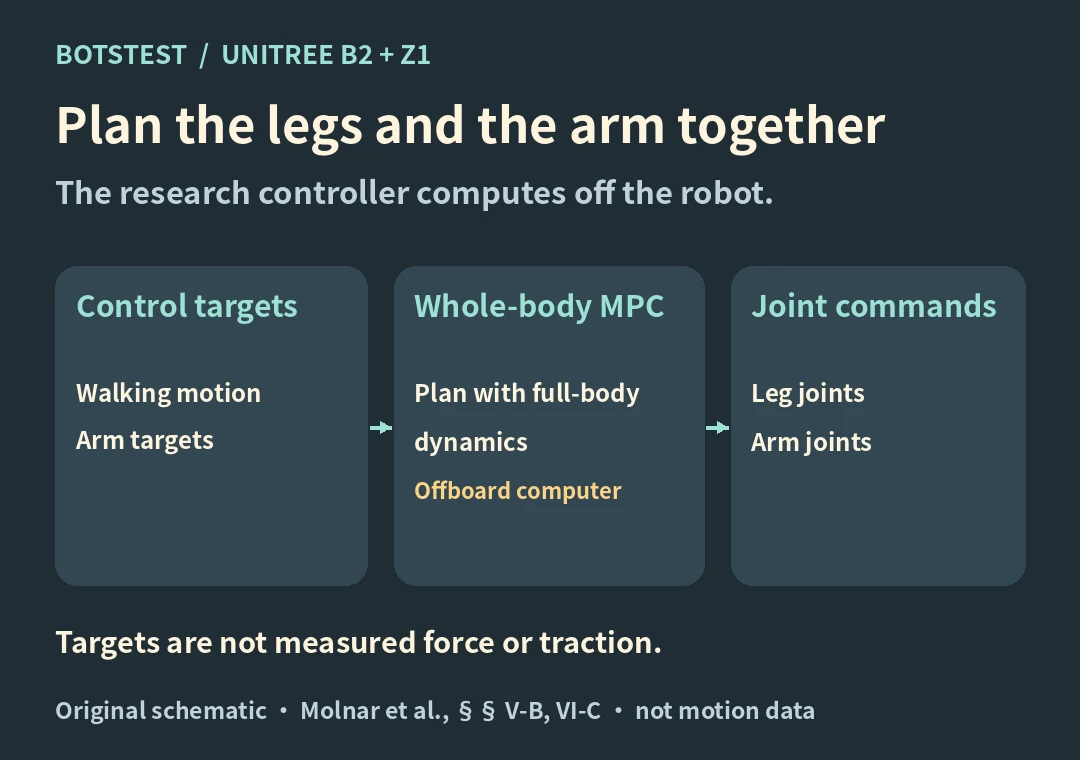
BotsTest conceptual diagram, not a measurement or the robot’s recorded path.
The 10 kg is the test load’s mass, not a measured pulling force or the arm’s payload rating. The paper does not publish a measured pulling force for this demonstration. BotsTest did not repeat the test.
Image credit: Lukas Molnar, Jin Cheng, Gabriele Fadini, Dongho Kang, Fatemeh Zargarbashi and Stelian Coros, arXiv:2511.19709v1, §VI-C and Figure 5, CC BY 4.0. Full left panel reproduced and placed in a new layout; no internal crop.
Turn the shortlist into a decision
Write down the task, operating conditions, success criteria and total ownership costs. Ask shortlisted suppliers to demonstrate your representative task, including failure recovery. Use the same acceptance test for each candidate.
Explore the full robotics directory →