Three small robots roll between obstacles in an indoor test area. If two see the same wall from different angles, what tells them it is the same wall? The TurtleBot3 Burger is a small mobile robot from the Open Robotics and ROBOTIS collaboration. GitHub user prakash-aryan published this three-robot project footage in an October 7, 2026 repository commit. That is the date of the published evidence, not the filming date. The room’s location is not identified by the source.
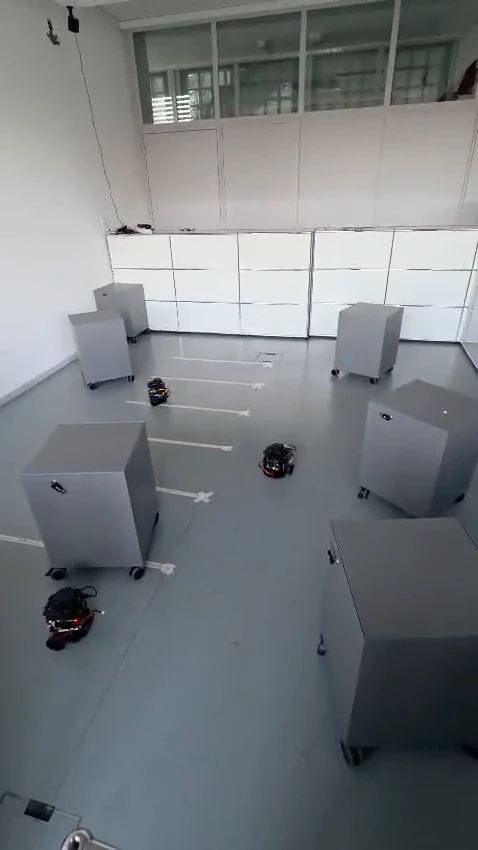
Author’s physical-robot demonstration, not a manufacturer or BotsTest test. Still extracted/reframed at 2.1 s from prakash-aryan, Multi-robot SLAM and Nav2 on TurtleBot3; Apache 2.0.
Agree on what “here” means
A planar LiDAR scan describes the world relative to the scanner. If one robot reports a wall straight ahead and another sees it to the left, those reports are not necessarily in conflict. First the robots need a common reference. In the author’s setup, configured starting poses and robot-specific coordinate transforms place local scan observations into a common frame. The relay also normalizes scan arrays where needed.
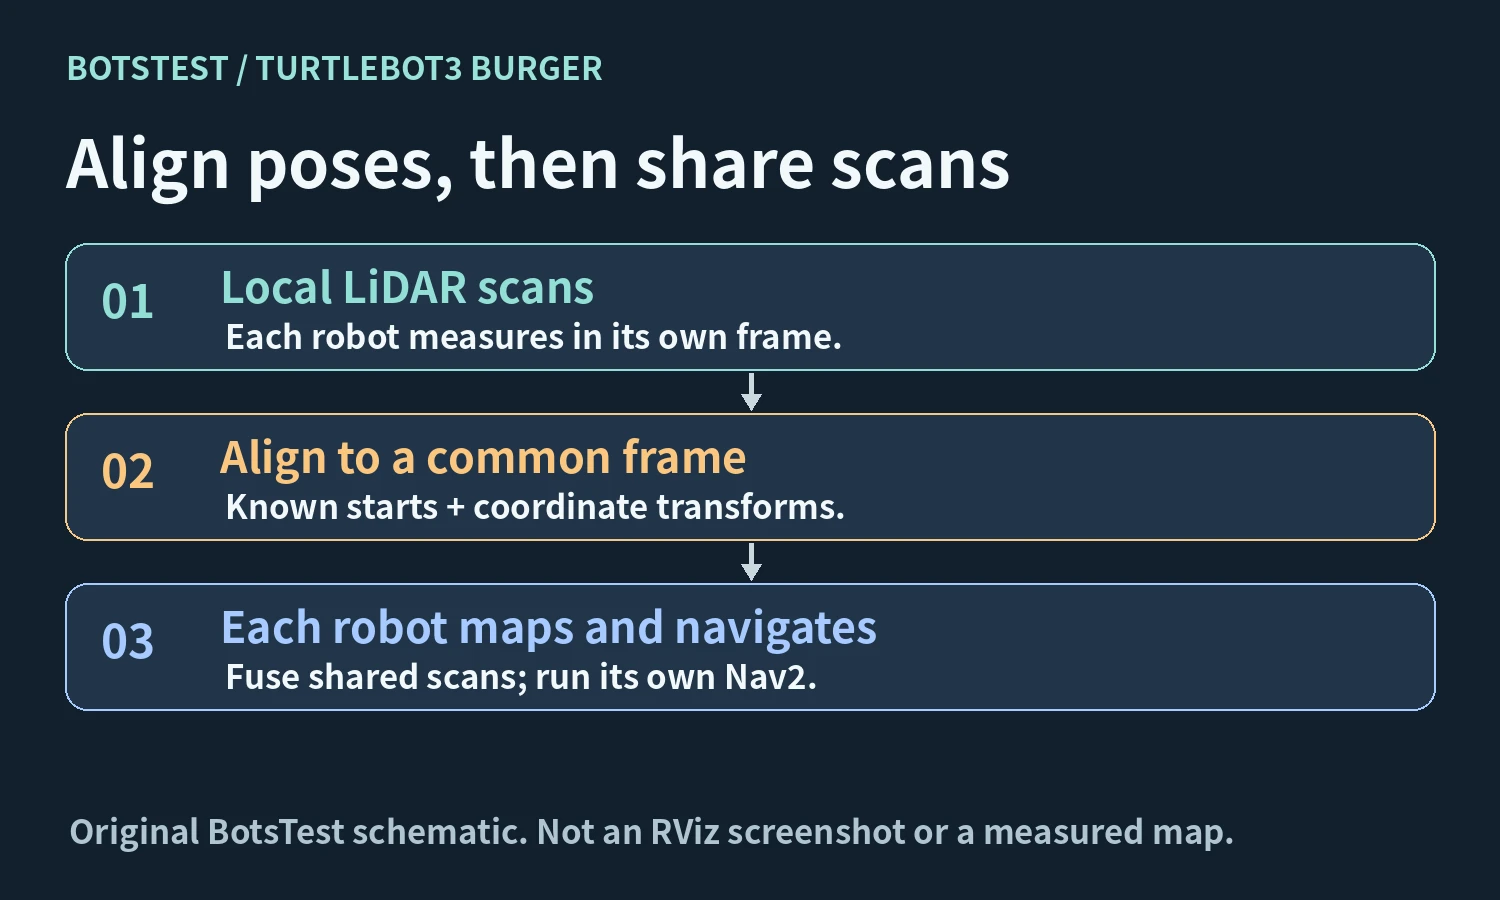
Original BotsTest schematic of the signal flow, not an RViz screenshot or measured map.
The multi-robot SLAM setup lets each robot build its map from aligned observations; it does not mean they all use one identical centrally served map. Each robot still runs a separate Nav2 stack for its own navigation. The project’s physical footage and separate RViz capture do not establish a synced view or demonstrate coverage gains, speedup, map accuracy, or guaranteed avoidance. This is an author demonstration, not a BotsTest measurement.
Turn the shortlist into a decision
Write down the task, operating conditions, success criteria and total ownership costs. Ask shortlisted suppliers to demonstrate your representative task, including failure recovery. Use the same acceptance test for each candidate.
Explore the full robotics directory →