Two robots can search different corners at once. But what happens when one discovers a job it can’t do alone? University of Virginia researchers Lauren Bramblett and Nicola Bezzo tested two physical Husarion ROSbot 2.0 ground robots in a 4 × 5.5 m indoor lab setup with Vicon motion capture and an assumed one-metre sensing and communication range. The robots split up, reconnected, completed the two-robot task and returned to base. The journal published the study on May 23, 2023; the authors did not specify the experiment date or exact room.
To cover more ground without keeping a continuous connection, the robots split up, and the one that found the task drove toward where it expected its partner to be so it could share the news at close range.
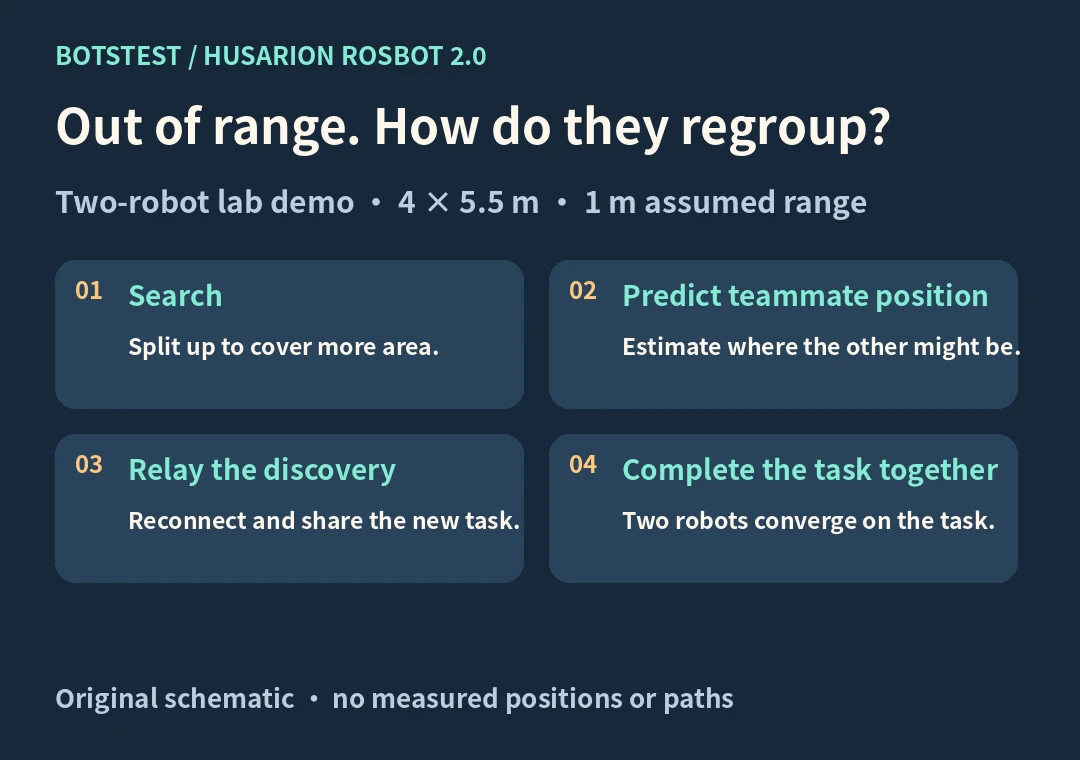
Original BotsTest schematic. The dashed line represents an intended rendezvous, not a measured route.
Getting back in touch is part of the job
The lead robot didn’t need to know its partner’s exact position at every moment. The planning method gives each robot an estimate of where the other might be based on its expected movement. In Figure 9, Robot 1 finds a task that needs two robots and plans to reconnect. Once the message gets through, both head to the task, finish it and return to base. The message is part of the mission: getting close enough to deliver it takes a trip of its own.
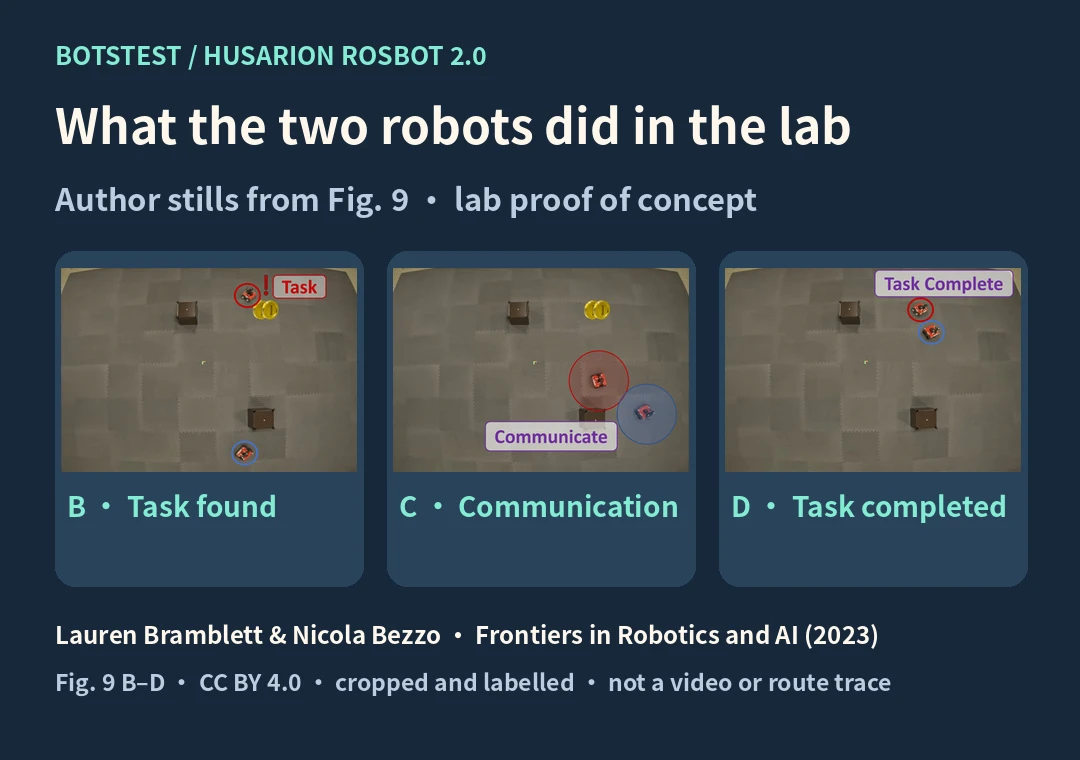
Cropped physical experiment image from Figure 9. This is a snapshot, not a continuous motion record.
One metre was a proof-of-concept setting, not a ROSbot 2.0 hardware limit. The paper’s simulation timings do not establish a speed gain in this physical run or performance in a real rescue. BotsTest didn’t repeat the experiment.
Figure 9 credit: Lauren Bramblett and Nicola Bezzo, Frontiers in Robotics and AI (2023), §7.1, Figure 9, CC BY 4.0, cropped.
Turn the shortlist into a decision
Write down the task, operating conditions, success criteria and total ownership costs. Ask shortlisted suppliers to demonstrate your representative task, including failure recovery. Use the same acceptance test for each candidate.
Explore the full robotics directory →