Would you trust an old phone to follow you to the coffee machine? Intel Labs researchers Matthias Müller and Vladlen Koltun tested a physical OpenBot rover on an indoor route from an office to a coffee machine and back. Using MobileNetV3, the Pixel 4 XL completed 3 of 3 trials; the Nokia 2.2 completed 0 of 3. The first preprint was posted August 24, 2020. It doesn’t give the test date or identify the building or city.
To turn a low-cost wheeled chassis into a robot that could follow a person, the researchers reused the phone’s camera and processor to detect the person and steer toward the center of the detection box.
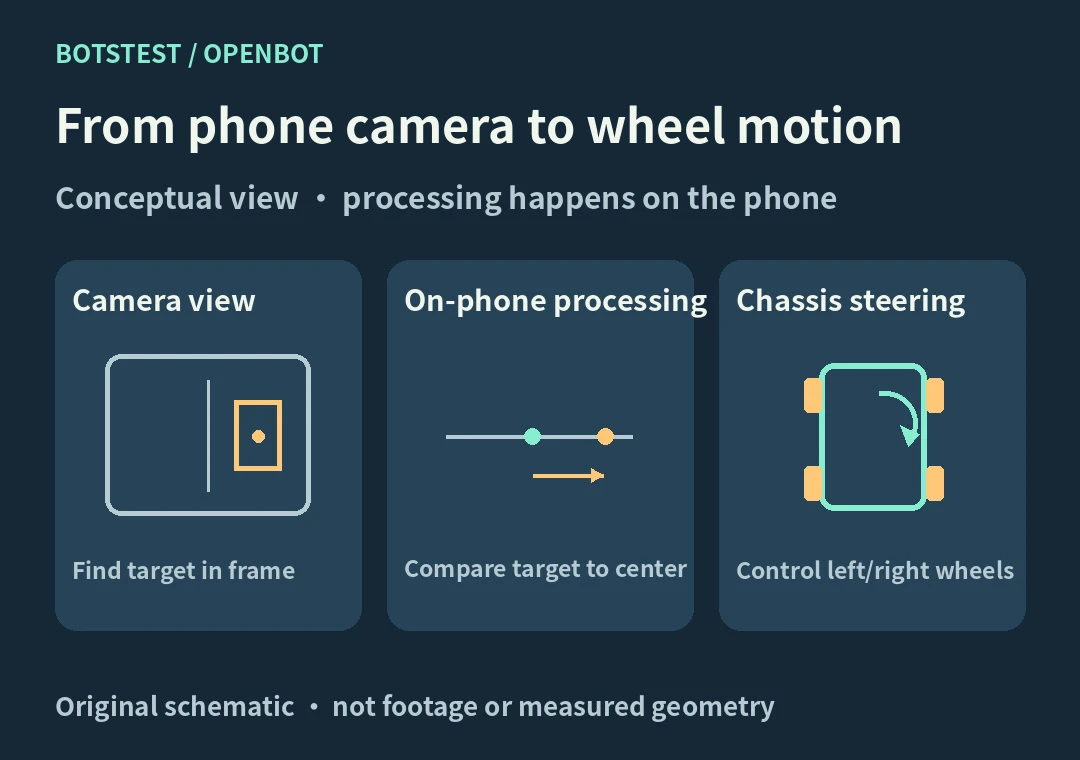
BotsTest schematic of the feedback loop, not footage of the trial.
The phone does more than send video
In the experiment, the detector looked for people. After choosing a target, the software used the center of its detection box as a steering cue. As the rover moved, each new image gave it another chance to correct. The phone handled the vision and control decisions; the body’s microcontroller handled low-level wheel control.
Half the route is not half the trials
The indoor round trip included four left turns and four right turns. With both phones restricted to one CPU thread, Table 3 reports 28 frames per second for the Pixel and 5 for the Nokia. The Pixel averaged 100% of the route; the Nokia averaged 50%, despite not completing a single run. Distance measures progress, while success means reaching the goal.
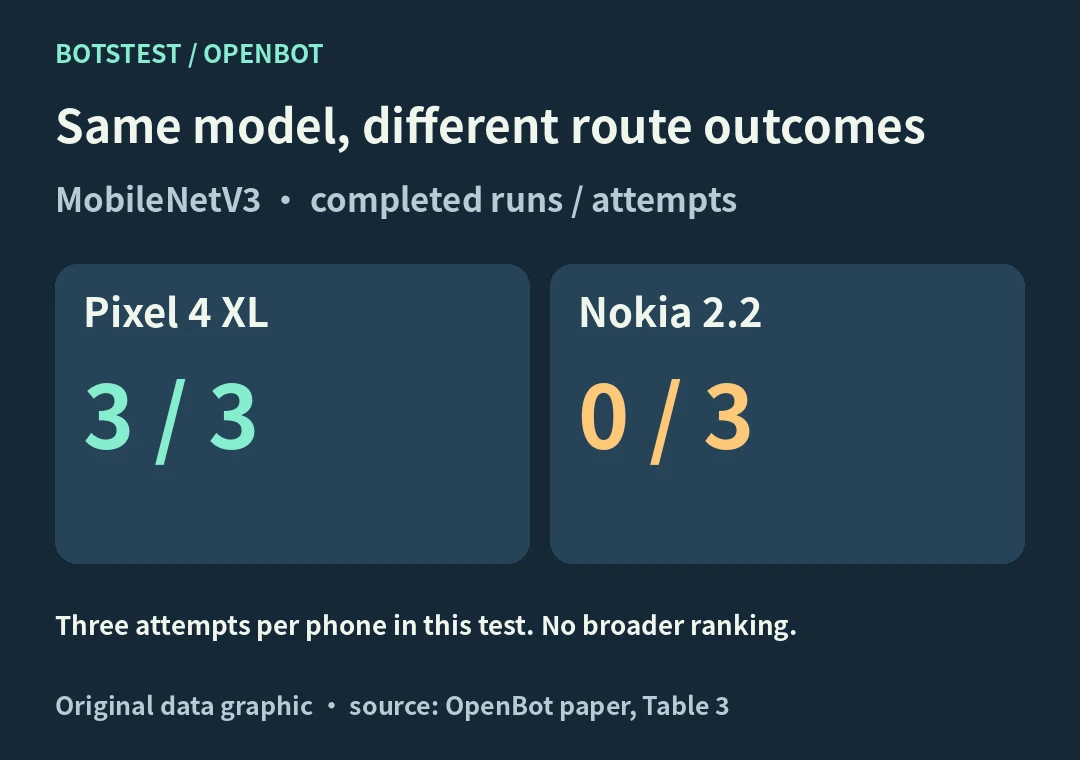
BotsTest chart of the authors’ MobileNetV3 results in Table 3. Each phone had three trials; completion and average route distance are separate measures.
A faster stream of detections can give the rover more opportunities to correct its steering. But this comparison doesn’t isolate frame rate as the sole cause or establish a cutoff that works everywhere. BotsTest didn’t repeat the experiment.
Original study, §§4.1–5.1 and Table 3 · Preprint history · OpenBot project
Turn the shortlist into a decision
Write down the task, operating conditions, success criteria and total ownership costs. Ask shortlisted suppliers to demonstrate your representative task, including failure recovery. Use the same acceptance test for each candidate.
Explore the full robotics directory →