When a network plug hits the edge of a router port, a person can change the angle and try again. For a robot training team, that moment can be worth recording. On September 3, 2026, AGIBOT posted its Theme 3 release for AgiBot World 2026, a dataset collected using physical AGIBOT G2 robots in real settings. The task list includes inserting a network cable into a router; the release does not name that task’s recording site, date, or result.
The first batch contains 11,430 physical trajectories across 14 industrial and household tasks. Among the recorded autonomous policy rollouts, AGIBOT reports 1,024 successful and 1,369 failed runs. Those are release-wide counts within one collection mode, not a router-cable score or a general G2 success rate. The team kept expert examples, what the policy actually tried, and separate traces where a person stepped in to correct it, so researchers can see where the policy goes off course and what the correction looks like.
Original BotsTest illustration, not real footage or a BotsTest trial.
Network-cable insertion is a task example. No cable-level result is reported.
Three kinds of records, three different questions
- Expert demonstrations: What does a reference execution look like?
- Autonomous rollouts: What does the current policy actually do, and what outcome gets recorded?
- Intervention traces: Where did an attempt go off course, when did a person take over, and what did the correction look like? This is a distinct collection mode, not something that happened on every unsuccessful run.
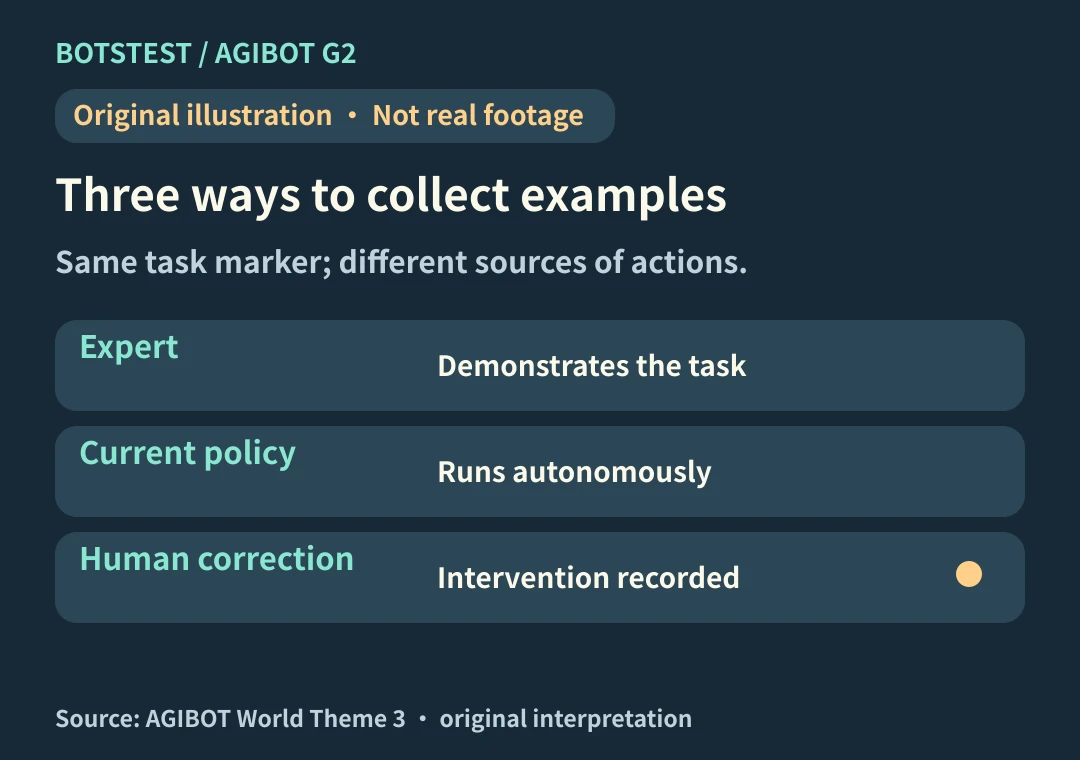
A human handoff belongs to the distinct intervention mode, not every failed run.
If you only collect polished demos, you can see where you want a robot to end up without seeing all the places its current policy might actually visit. Failed runs and handoff points make some of those other states visible. This release does not establish how much better a model gets from including them.
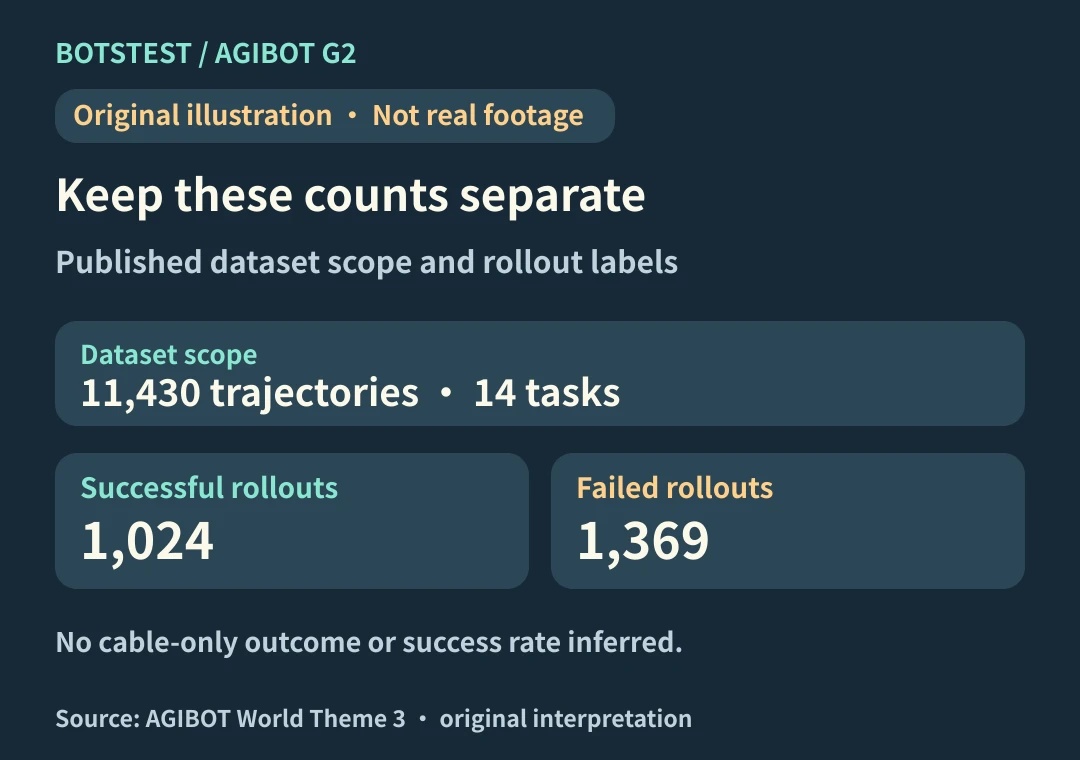
These counts describe the batch, not the example task.
The useful idea is to keep records of where behavior goes wrong, not just where it ends well. The plug graphic is an original illustration of a task type, not a reconstruction of a particular recording.
AGIBOT Theme 3 release · Official dataset card · Task metadata
Original BotsTest illustrations, not real footage or a BotsTest trial. For rights or attribution concerns, use this platform’s available contact or rights-reporting channel. We’ll review and correct, replace, or remove the material as appropriate.
Turn the shortlist into a decision
Write down the task, operating conditions, success criteria and total ownership costs. Ask shortlisted suppliers to demonstrate your representative task, including failure recovery. Use the same acceptance test for each candidate.
Explore the full robotics directory →