Can a robot make the same walk look different just by raising or lowering its head? Masato Kobayashi tested a physical Open Duck Mini V2 in a controlled indoor setup, commanding it to walk straight ahead for five seconds under each of three style labels. The recorded head angle was highest for Happy, in the middle for Neutral and lowest for Sad. The first EmoLo preprint was posted April 1, 2026; the exact test date and room were not disclosed.
To vary the look of the walk without switching between three controllers, Kobayashi trained one controller in simulation to take a style label alongside the walking command, then ran it onboard as an ONNX model with no additional tuning on the real robot.
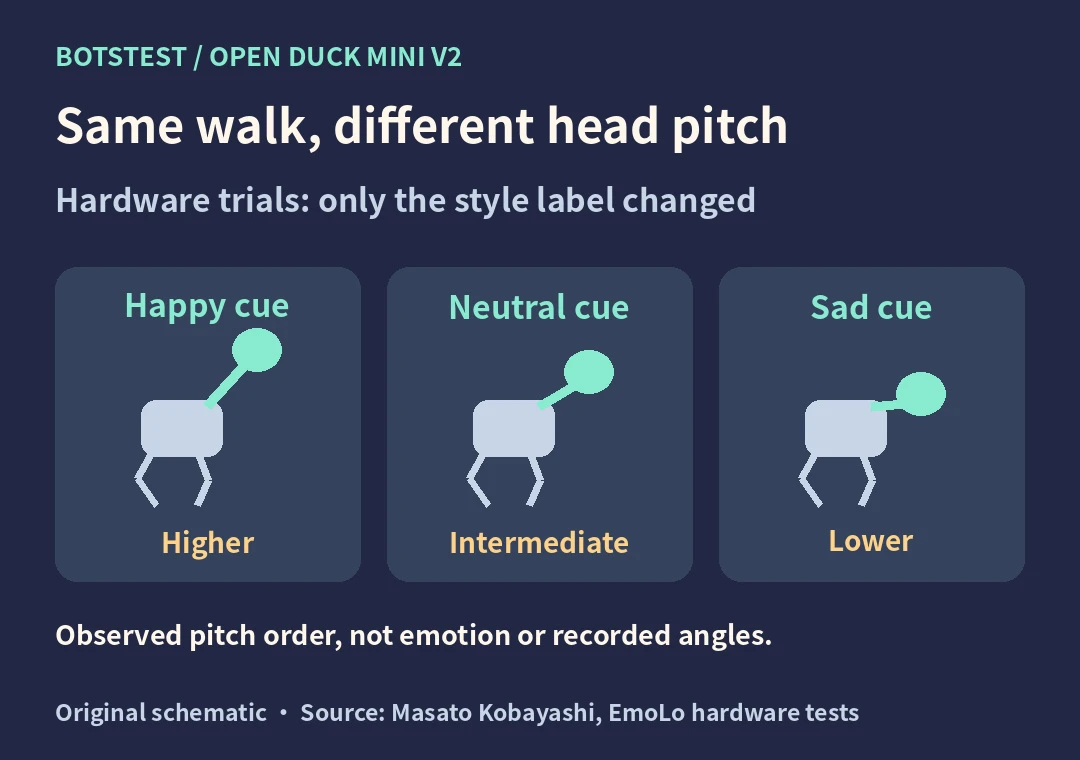
BotsTest schematic of the reported ordering. The drawn postures are illustrative and do not encode measured angles.
The walk stays the same task. The head tells a different story.
The three instructions didn’t ask the robot to speed up, turn or head to a different place. They asked for a different walking style under the same forward command. The training encouraged different head postures while keeping the basic walking objective. On the physical robot, the head-angle logs kept that ordering. What changed in the evidence is the head posture, not a feeling.
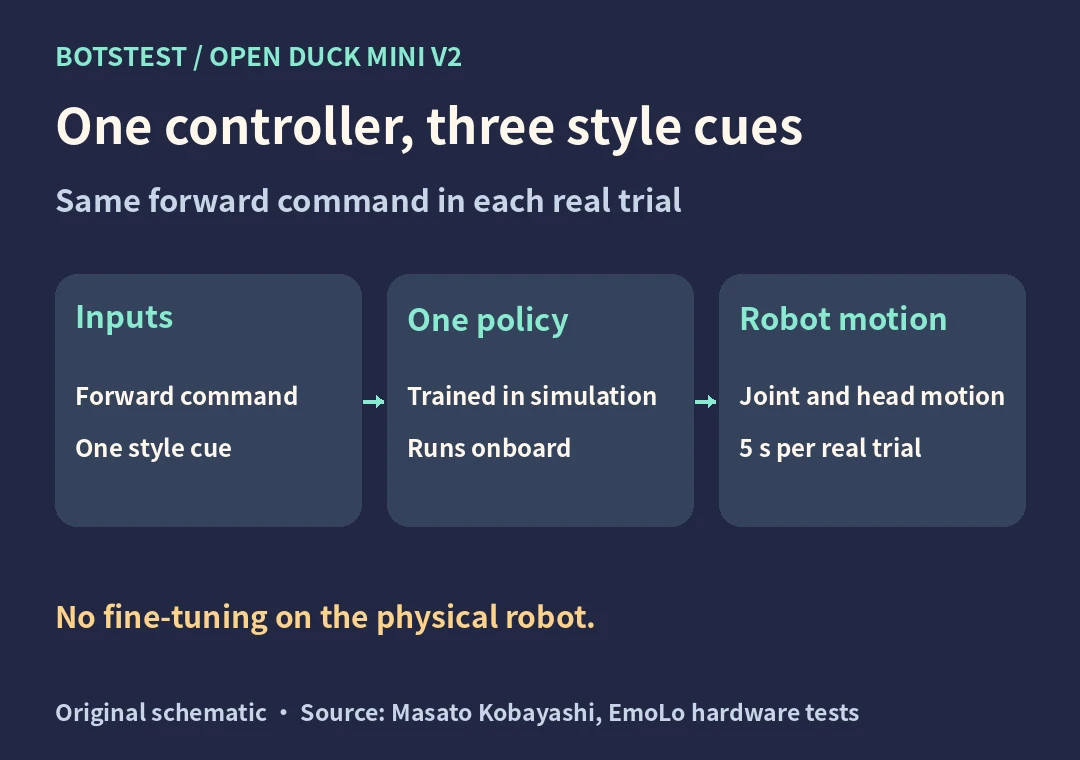
BotsTest conceptual illustration, not a figure or photograph from the study.
This short trial does not establish a speed difference, performance on unfamiliar terrain or an emotional state. BotsTest did not repeat the experiment.
EmoLo preprint, hardware sections and Figures 6–7 · Author’s project page · Preprint version record
Turn the shortlist into a decision
Write down the task, operating conditions, success criteria and total ownership costs. Ask shortlisted suppliers to demonstrate your representative task, including failure recovery. Use the same acceptance test for each candidate.
Explore the full robotics directory →