The start button was the robot itself. In early 2015, KUKA’s robot production team put an LBR iiwa mounted on a flexFELLOW unit to work at its own factory in Augsburg, Germany. After a worker touched it to cue the program, the iiwa tightened the screws securing a gear unit on a KR QUANTEC link arm. KUKA did not specify the day it went into service.
To take repetitive tightening off the worker’s hands, the robot used the touch as a start cue, calibrated itself at the workstation and then tightened the prepared screws in a set order.
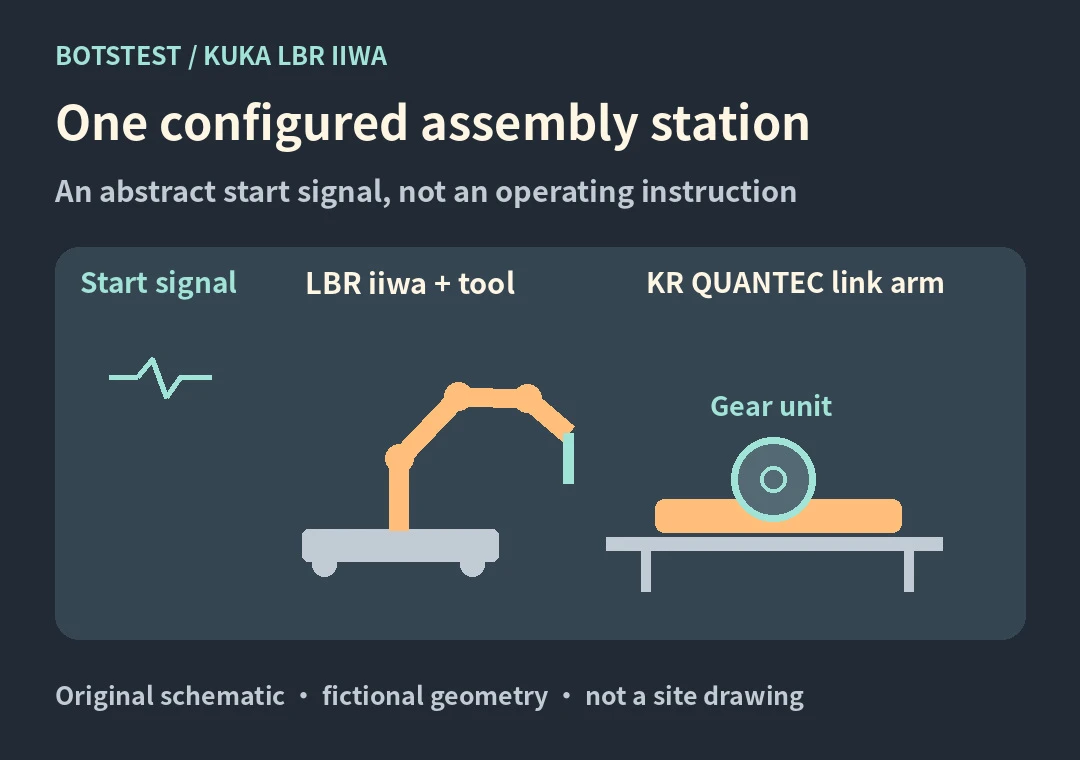
BotsTest workcell schematic, not a photograph or a safety instruction.
Two robots, two different jobs
The iiwa was the assembly assistant. The QUANTEC was the larger robot being built, and the link arm was the part resting on the support table. The worker loaded the arm with the screws already inserted; a separate touch cued work on the next link arm. KUKA’s annual report captions Kai Demele and Jasmin Bandasch loading a link arm, but does not identify who gave the start cue.
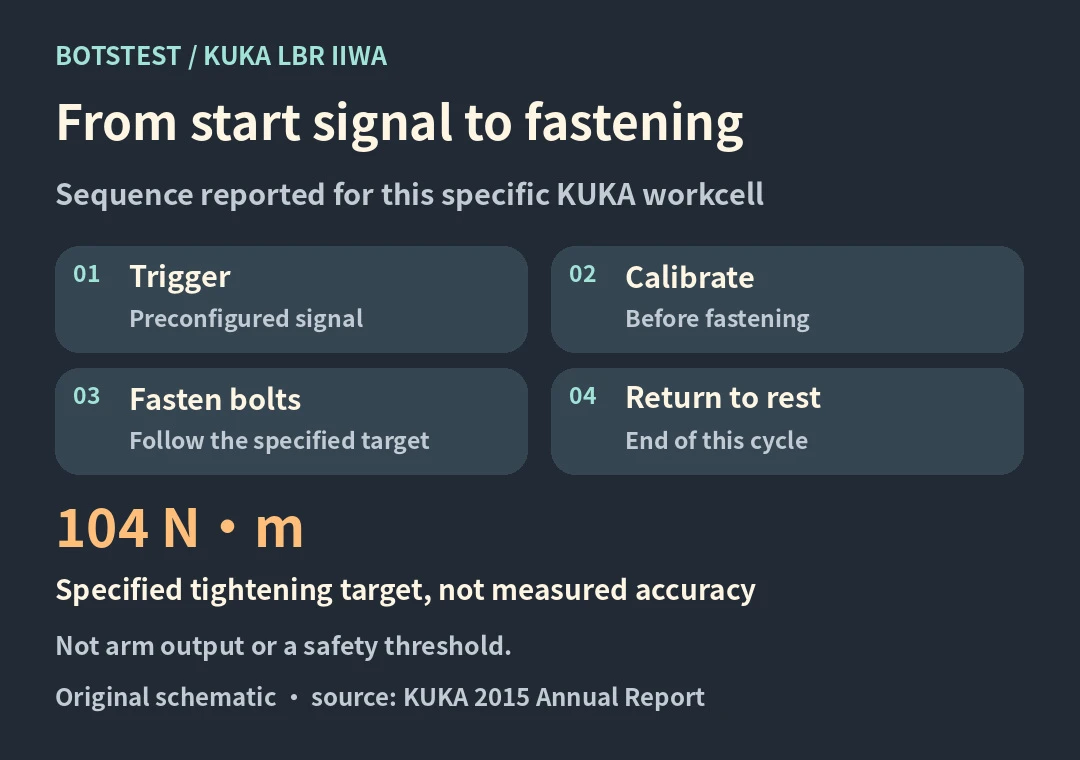
BotsTest process schematic. 104 N·m was the target torque for this operation.
What 104 N·m means
KUKA gives 104 N·m as the fastening torque specified for that job. It is not a measurement of how close each screw came to the target, or a rating for an iiwa joint. The revealing detail is the handoff: the person decided when a part was ready; the machine handled the sequence. The touch cue describes this configured cell, not a general instruction to touch a robot.
Sources: KUKA’s deployment case, KUKA Industry 4.0 archival booklet, pp. 72–73, and KUKA’s FY2015 annual report.
Turn the shortlist into a decision
Write down the task, operating conditions, success criteria and total ownership costs. Ask shortlisted suppliers to demonstrate your representative task, including failure recovery. Use the same acceptance test for each candidate.
Explore the full robotics directory →