The refrigerator door opens, but the robot’s gripper doesn’t close. Hello Robot says the gripper stayed open throughout its Stretch 4 fridge task. The interesting question isn’t how tightly it squeezes. It’s how it engages the handle and follows it as the door swings.
The motion to watch is after contact
In the head-left camera view from Hello Robot’s training dataset, the gripper reaches the handle while the door is still closed. A moment later the shelves are visible. That contrast shows something a close-up of the initial contact cannot: the door actually swung open. This is a human-teleoperated training demonstration, not an autonomous test.
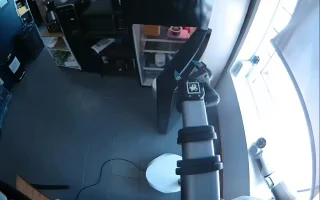
The open door reveals the shelves. Human-teleoperated training demonstration. Unmodified extracted still from Hello Robot Inc., stretch4_open_fridge, head-left camera, revision 92544014502045e27bb1bb375e70e4155b29f02c, Apache-2.0.
Think of the handle as the tip of a clock hand. The hinge is the pivot; the moving door sets the handle’s path. A robot has to accommodate that changing position if it wants to keep pulling. A mobile manipulator can change its end-effector position by moving the arm, repositioning the base, or coordinating both. The diagram explains the geometry, not the controller, measured trajectory, or forces in this recording. The source’s account suggests that the robot can engage the handle without pinching it; the footage does not establish the exact contact point.
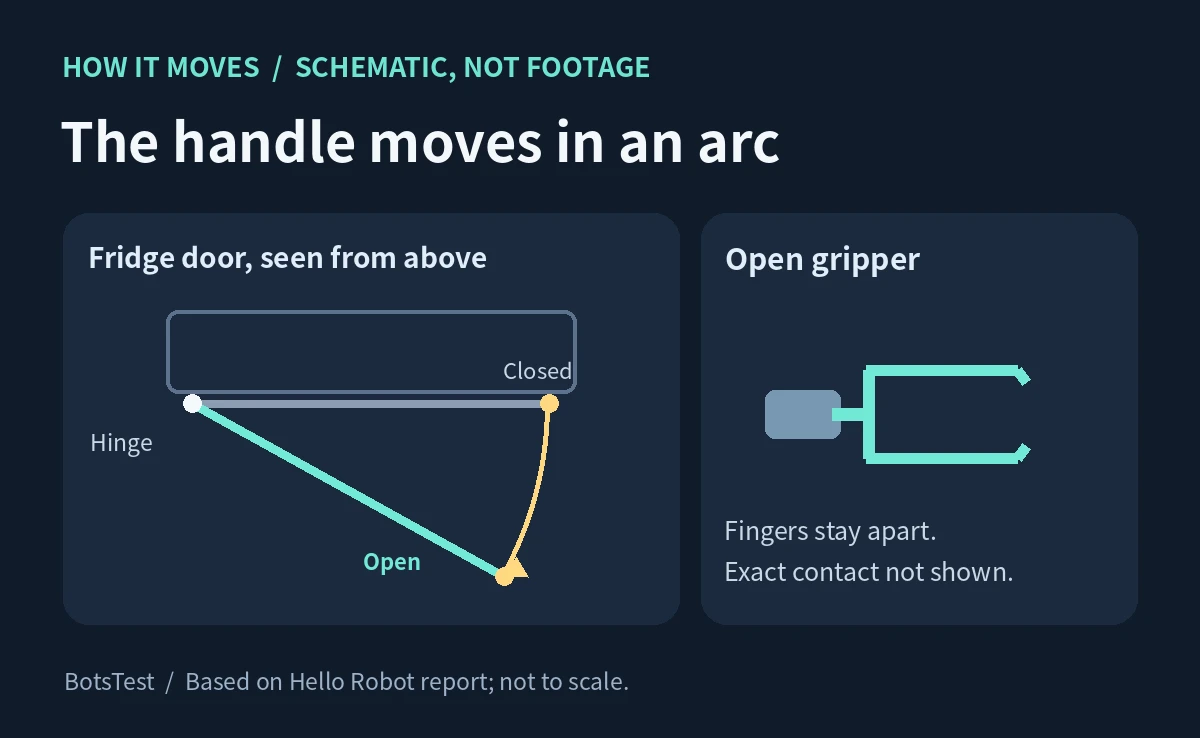
The hinge fixes the pivot, so the handle follows an arc. Original BotsTest schematic; not a measured trajectory.
What the trial numbers actually count
Hello Robot collected 100 puppet-teleoperated training demonstrations, varying the arm and base starting poses. These are examples for learning, not successes out of 100 autonomous attempts. In a separate hardware evaluation, Hello Robot counted whether the door opened. Its Diffusion Policy opened this refrigerator in 9 of 10 attempts while running on the robot’s Jetson Orin NX. That is a small, manufacturer-reported test on this setup, not a BotsTest retest or a prediction for another fridge.
For a useful test of your own, record the final open-or-closed result, but log the first break in the sequence too: did it miss the handle, lose contact during the swing, or fail to open far enough for a threshold you set in advance? Two failures can look identical at the finish and tell you very different things about what to fix.
Hello Robot’s LeRobot integration report · BotsTest’s Hello Robot Stretch listing
Turn the shortlist into a decision
Write down the task, operating conditions, success criteria and total ownership costs. Ask shortlisted suppliers to demonstrate your representative task, including failure recovery. Use the same acceptance test for each candidate.
Explore the full robotics directory →