What if the first step is hard to see from where you stand? Xincheng Tang and colleagues at Shanghai Jiao Tong University tested a physical Unitree Go2 on 55° open-riser stairs. The full StairMaster method succeeded in 19 of 30 runs, compared with 5 of 30 when the researchers omitted simulated depth noise from training but kept the camera. The results are reported in the July 29, 2026 revision of the arXiv preprint; the exact test date and location weren’t disclosed.
With gaps between the treads and little room to place a foot, the robot tipped its body upward before the first step in one reported run, changing where its front-mounted depth camera looked.
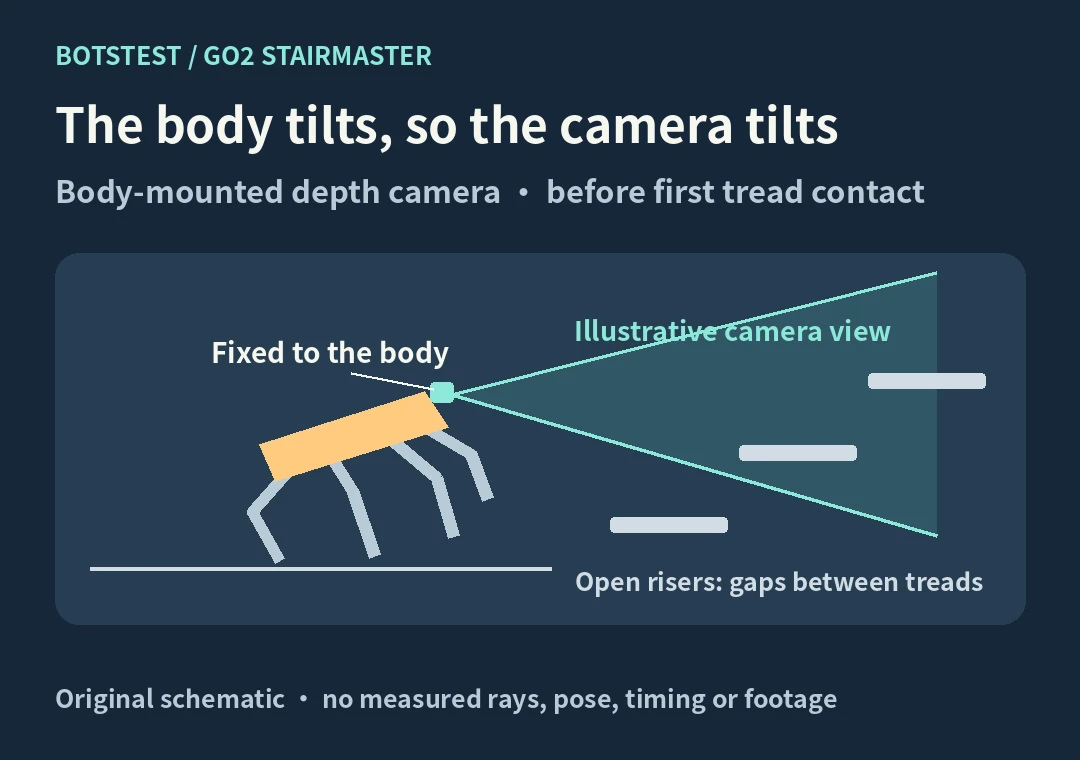
BotsTest schematic, not a paper figure, trial photograph or measured robot angle.
The first step changes the view
Look at the robot before it steps: raising the front of its body points the depth camera toward more of the staircase. The controller uses depth observations and recent history when planning the motion. That describes one mechanism shown in the paper’s Figure 5. The counts below answer a different question: how often each training variant completed the same physical staircase.
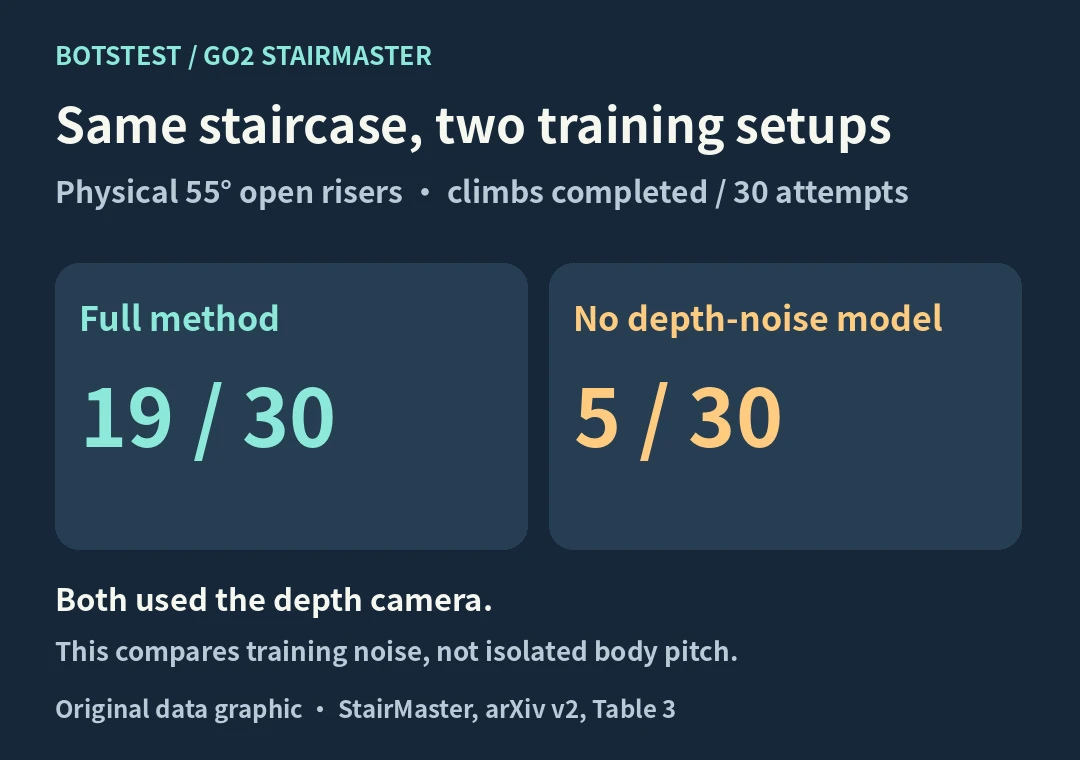
BotsTest chart based on StairMaster v2, Table 3. Both conditions retained the depth camera; each had 30 runs.
One example of the robot tilting upward doesn’t show that the tilt alone produced the difference in completion. These counts describe the reported setup, not a guarantee for other staircases. BotsTest did not repeat the test.
StairMaster preprint v2: real-world experiments, Table 3 and Figure 5
Turn the shortlist into a decision
Write down the task, operating conditions, success criteria and total ownership costs. Ask shortlisted suppliers to demonstrate your representative task, including failure recovery. Use the same acceptance test for each candidate.
Explore the full robotics directory →