The same kind of mesh bag can look wide and flat on the belt, then arrive tall and lopsided on the next pick. At its Arvin-area plant south of Bakersfield, California, potato packer Tasteful Selections installed five FANUC M-3iA delta robots fitted with Soft Robotics mGrip grippers to load bags of small potatoes into boxes. FANUC’s case study, published October 15, 2021, lists the M-3iA/6S; it does not give commissioning or filming dates. In its October 27, 2021 account, Soft Robotics reported more than 45 bags per minute for the work cell, not for a single robot.
As the upstream line sped up, hand-packing became a bottleneck and the bags kept changing shape, so the setup used machine vision to locate each bag and flexible pneumatic fingers to close around its outline.
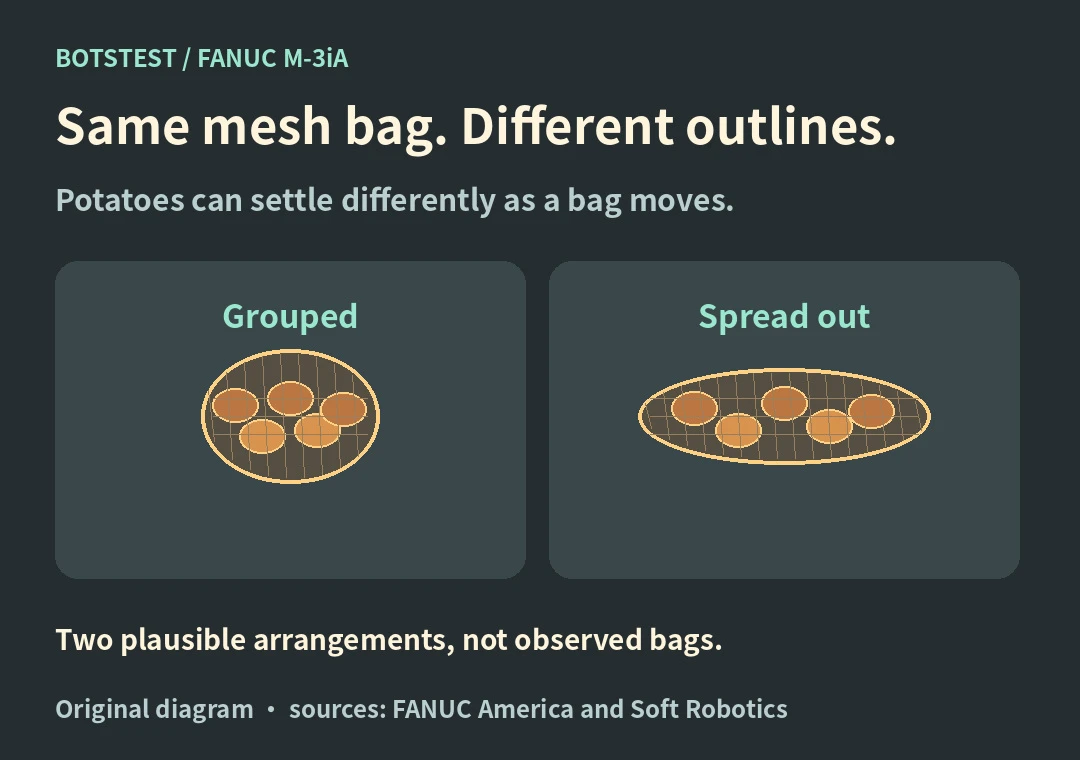
BotsTest illustration. The outlines and grip positions are not measured from the line.
The camera finds the bag. The soft fingers deal with the shape.
Picture one bag with the potatoes spread out and another with most of them clustered to one side. The vision system guides the pick, but it does not make the bags sit in a uniform shape. The mGrip fingers bend around the bag as they close, easing how precisely the tool has to line up with its outline. The arm then lifts the bag and places it in a box. The shapes here are illustrations, not measurements from the line.
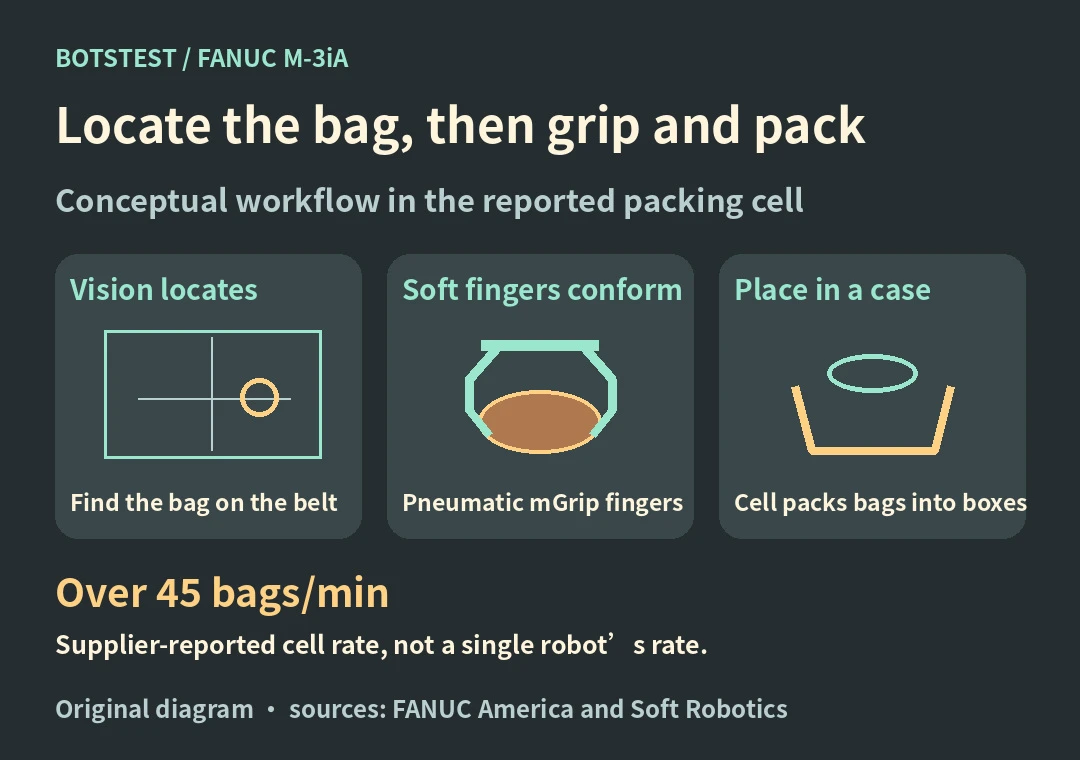
Soft Robotics reported more than 45 bags per minute for the work cell, not a rated speed for an individual robot.
This is case packing: putting bags in boxes. Stacking those boxes on pallets is a different stage. The supplier account doesn’t give a measured single-robot rate or a manual baseline. BotsTest did not retest the line.
FANUC deployment case study · Soft Robotics report on the gripper and cell result · Tasteful Selections on its production facilities
Turn the shortlist into a decision
Write down the task, operating conditions, success criteria and total ownership costs. Ask shortlisted suppliers to demonstrate your representative task, including failure recovery. Use the same acceptance test for each candidate.
Explore the full robotics directory →