Boston Dynamics makes Stretch to move cartons in warehouses. But how does it pick up a box without wrapping fingers around it? Watch where the suction cups land.
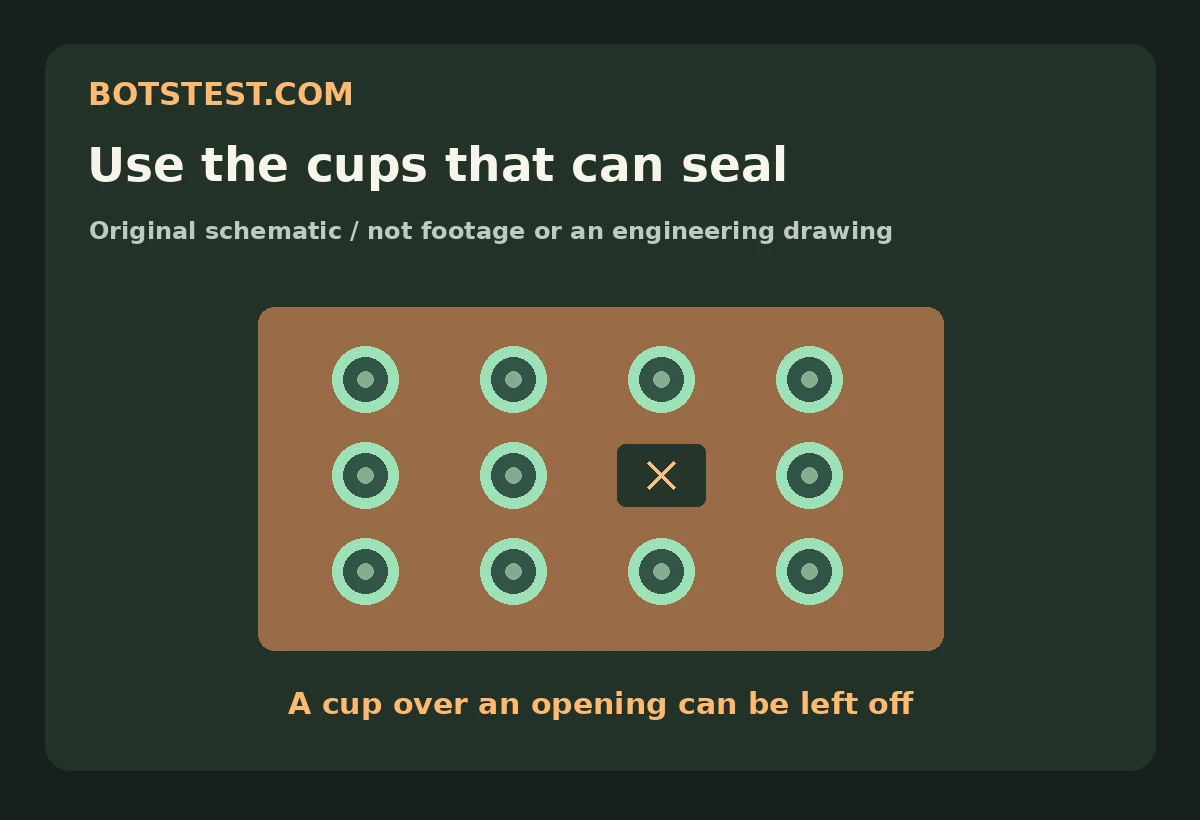
Original BotsTest illustration; not machinery footage or a measured test.
Use the cups that can seal
In Boston Dynamics’ account of Arvato’s first-generation deployment, Stretch picks cartons and places them on a conveyor. The cups on its vacuum gripper can be activated individually. If a cup would sit over an opening, the gripper can instead use cups that have a surface to seal against.
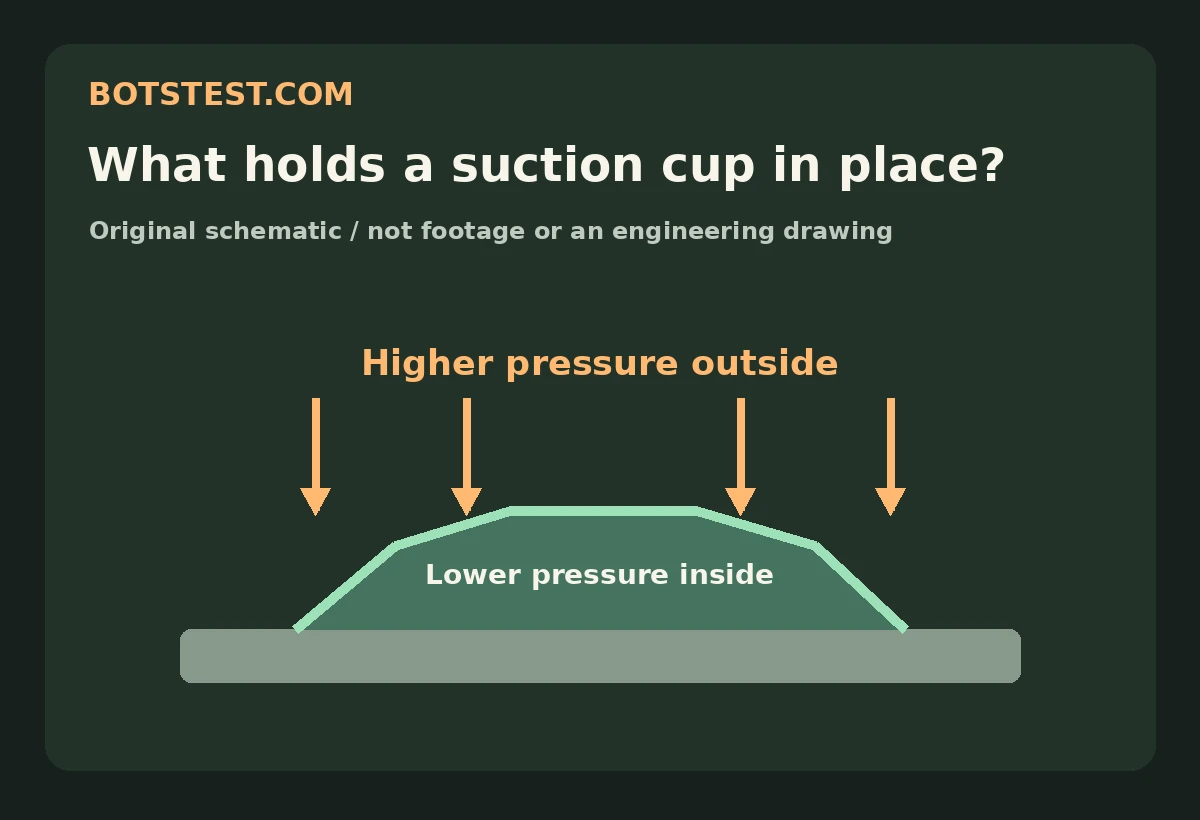
The pressure difference shown illustrates the principle, not measured vacuum or holding force.
That is the interesting detail: the gripper does not need every cup to touch the box. It needs the enabled cups to make a usable seal. The illustrations explain the mechanism; they do not establish how fast or reliably the robot works. BotsTest did not run this deployment.
Turn the shortlist into a decision
Write down the task, operating conditions, success criteria and total ownership costs. Ask shortlisted suppliers to demonstrate your representative task, including failure recovery. Use the same acceptance test for each candidate.
Explore the full robotics directory →