 代码仓库
科研与学习 / 科研
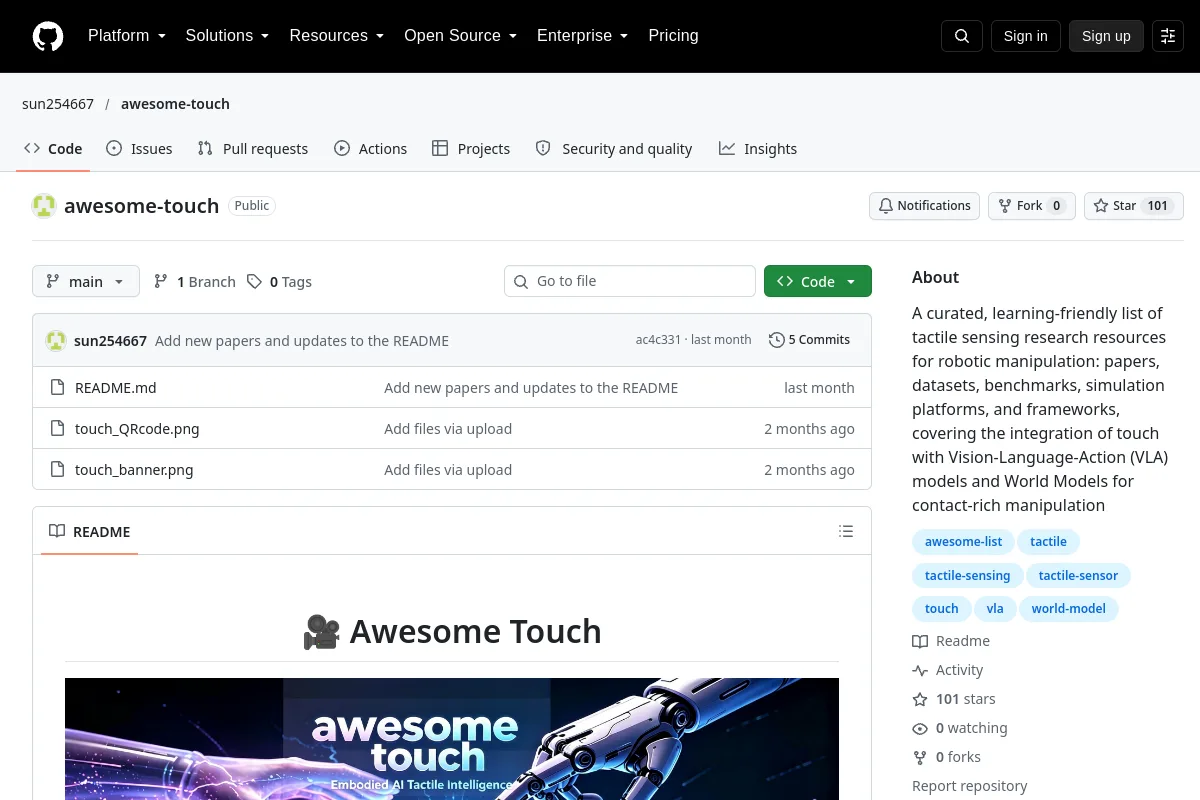
awesome-touch · sun254667
用于机器人操作的触觉传感研究资源的精心策划的、易于学习的列表:论文、数据集、基准、模拟平台和框架,涵盖……的集成
概述
A curated, learning-friendly list of tactile sensing research resources for robotic manipulation:papers, datasets, benchmarks, simulation platforms, and frameworks, covering the integration of…<br><br>Publisher purpose:A curated, learning-friendly list of tactile sensing research resources for robotic manipulation:papers, datasets, benchmarks, simulation platforms, and frameworks, covering the integration of touch with Vision-Language-Action (VLA) models and World Models for contact-rich manipulation<br><br>Use the source to explore robotics concepts, examples and references. Source material may be historical; check the applicable version and context.
项目信息
- 维护者
- sun254667
- 主要语言
- Not specified
- 存储库代码许可证
- 未指定
- 模型重量许可证
- 未记录
- 数据集许可
- 未记录
- 硬件设计许可证
- 未记录
- 维护
- 未存档在最后记录的元数据中
- 最后观察到的存储库推送
- 2026-09-07
代码许可不会自动涵盖模型权重、数据集或硬件设计。未记录的许可证详细信息需要与发布者确认。
文档部分
- 🎥 Awesome Touch
- Table of Contents
- 📚 Surveys & Overviews
- 🤖 Tactile VLA Models
- 2.1 Unified Vision-Tactile-Language-Action Frameworks
- 2.2 Tactile-Enhanced VLA with Foundation Models










