 代码仓库
数据集 / 科研
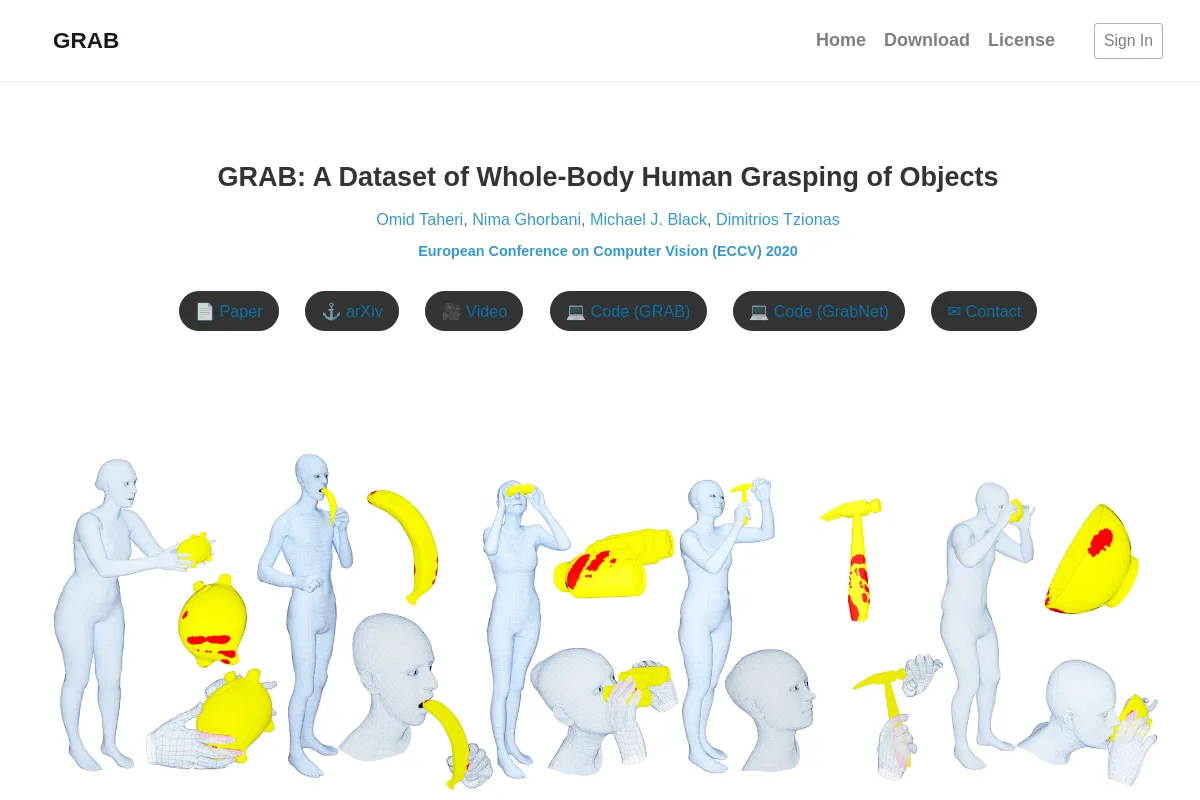
GRAB
用于研究对象交互的全身人体抓取数据。
概述
Whole-body human grasping data for studying object interaction.
Inspect task coverage, robot embodiments, observation/action formats and data licenses. Check collection conditions and splits before using demonstrations for training or evaluation.










