 代码仓库
科研与学习 / 科研
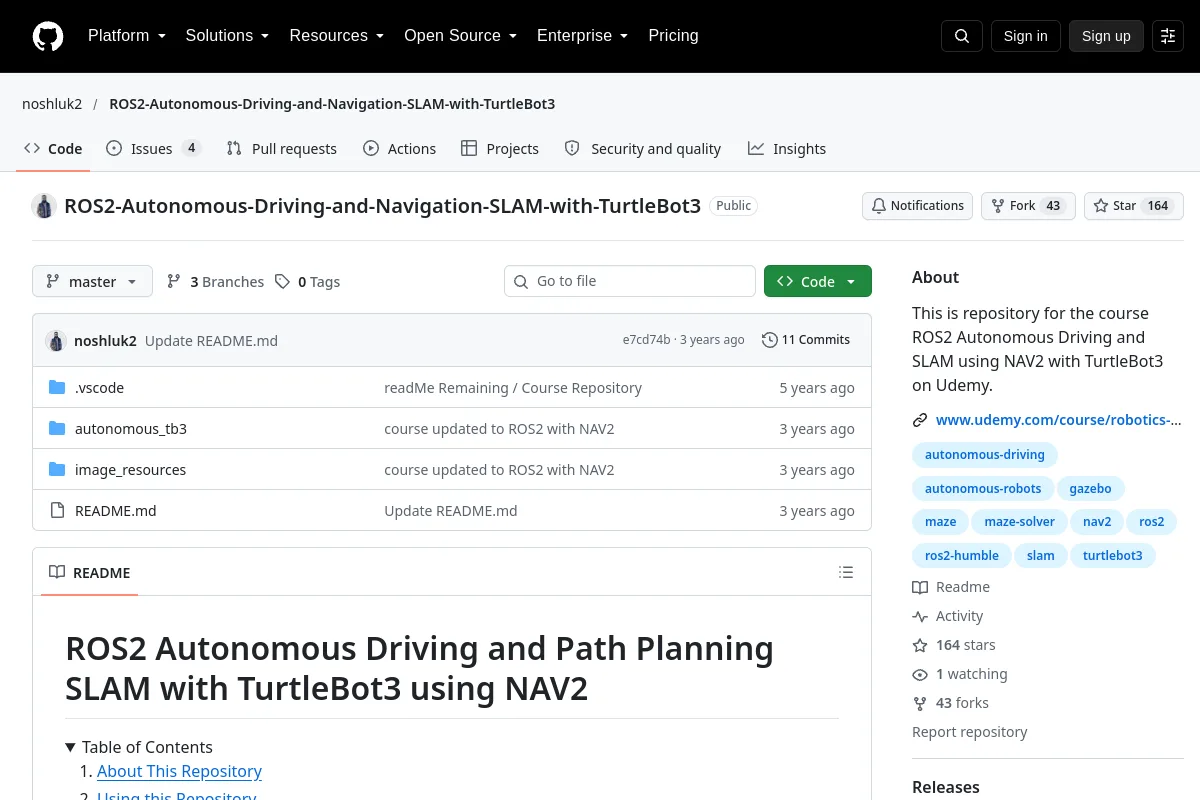
ROS2-Autonomous-Driving-and-Navigation-SLAM-with-TurtleBot3 · noshluk2
这是 Udemy 上使用 NAV2 和 TurtleBot3 的 ROS2 自动驾驶和 SLAM 课程的存储库。
概述
This is repository for the course ROS2 Autonomous Driving and SLAM using NAV2 with TurtleBot3 on Udemy.<br><br>Publisher purpose:This is repository for the course ROS2 Autonomous Driving and SLAM using NAV2 with TurtleBot3 on Udemy. <br><br>Use the source to explore robotics concepts, examples and references. Source material may be historical; check the applicable version and context.
项目信息
- 维护者
- noshluk2
- 主要语言
- Python
- 存储库代码许可证
- 未指定
- 模型重量许可证
- 未记录
- 数据集许可
- 未记录
- 硬件设计许可证
- 未记录
- 维护
- 未存档在最后记录的元数据中
- 最后观察到的存储库推送
- 2023-05-26
代码许可不会自动涵盖模型权重、数据集或硬件设计。未记录的许可证详细信息需要与发布者确认。
文档部分
- ROS2 Autonomous Driving and Path Planning SLAM with TurtleBot3 using NAV2
- About this Repository
- Using this Repository
- Course Workflow
- Features
- Pre-Course Requirments










