 Repository
Hardware / Open source
Ragtime_Panthera · Ragtime-LAB
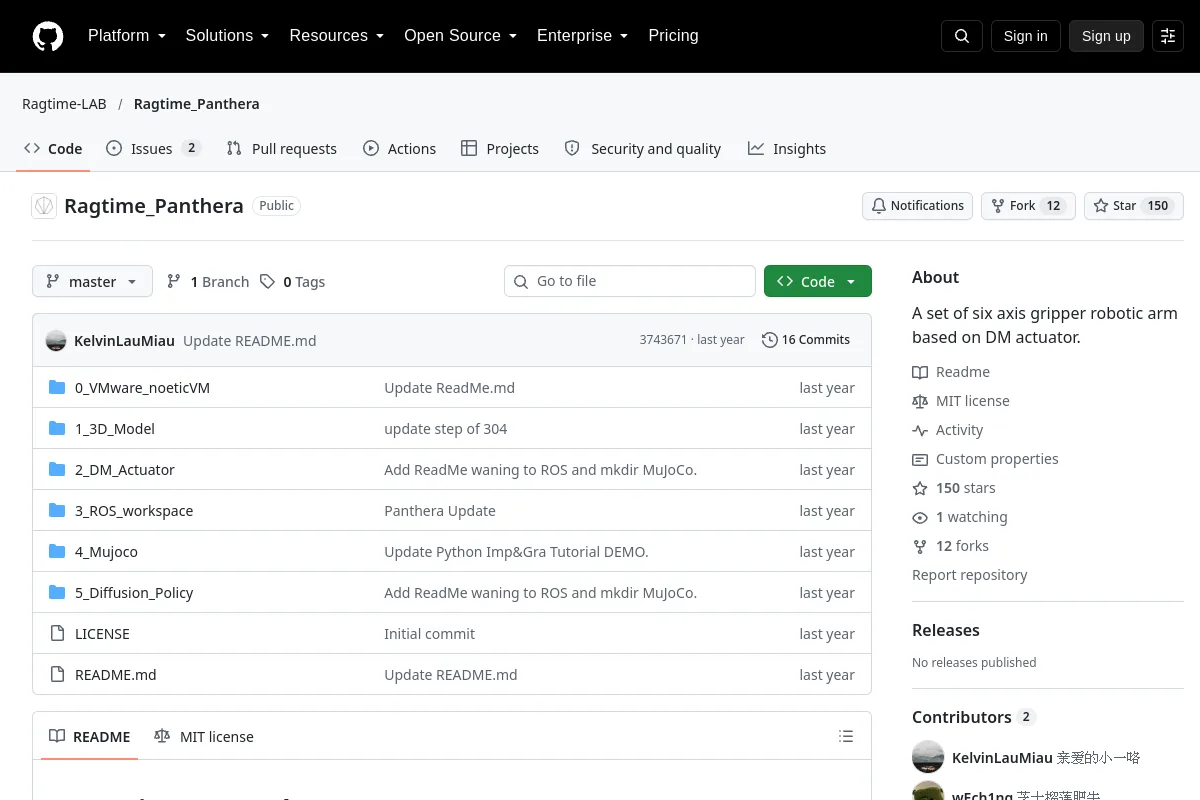
A set of six axis gripper robotic arm based on DM actuator.
Overview
A set of six axis gripper robotic arm based on DM actuator.
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Project information
- Maintainer
- Ragtime-LAB
- Primary language
- C++
- Repository code license
- MIT
- Model-weight license
- Not recorded
- Dataset license
- Not recorded
- Hardware design license
- Not recorded
- Maintenance
- Not archived in the last recorded metadata
- Last observed repository push
- 2025-08-22
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
- Ragtime_Panthera
- Acknowledgements
- Tutorials
Browse this resource’s categories
Explore related collections
Robot arms for learning ↗More in Hardware
Repository
 Repository
 Open source
OpenCatEsp32-Quadruped-Robot · PetoiCamp
An ESP32-based open source quadruped robot pet framework for developing Boston Dynamics-style four-legged robots that are perfect for STEM, coding & robotics education, IoT robotics applications…
DIY & education hardware Repository
 Open source
OpenCat-Quadruped-Robot · PetoiCamp
An open source quadruped robot pet framework for developing Boston Dynamics-style four-legged robots that are perfect for STEM, coding & robotics education, IoT robotics applications, AI-enhanced…
DIY & education hardware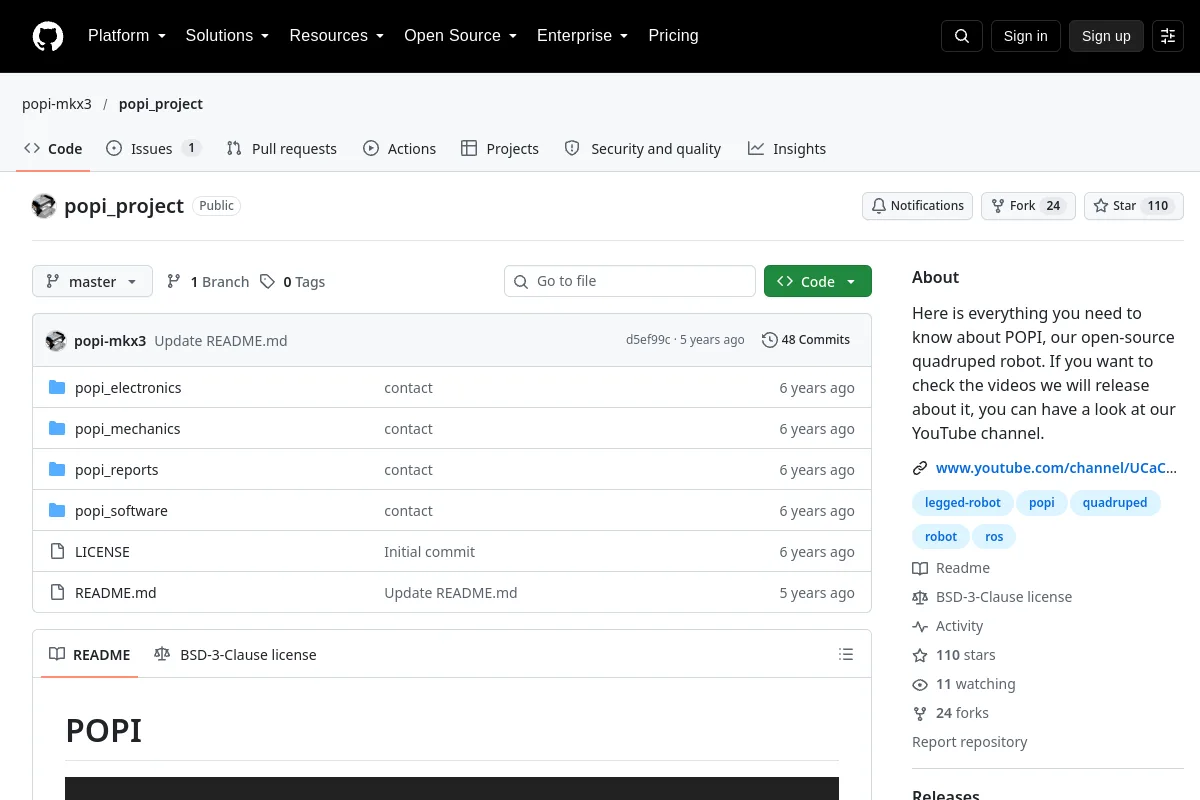 Repository
 Open source
popi_project · popi-mkx3
Here is everything you need to know about POPI, our open-source quadruped robot. If you want to check the videos we will release about it, you can have a look at our YouTube channel.
DIY & education hardware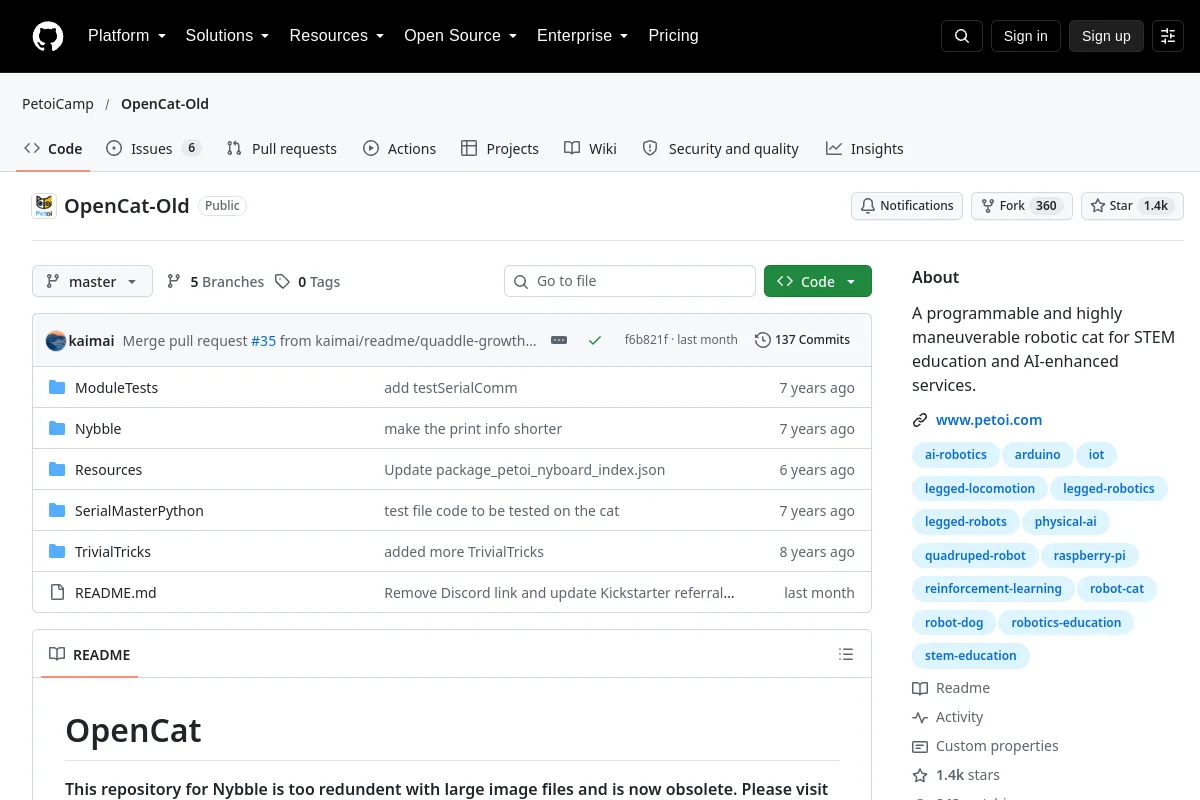 Repository
 Research
OpenCat-Old · PetoiCamp
Historical reference: A programmable and highly maneuverable robotic cat for STEM education and AI-enhanced services.
DIY & education hardware Repository
 Research
open quadruped · adham-elarabawy
open-quadruped is a 3D-printed quadrupedal robot project with gait generation and body-pose control.
DIY & education hardware