 代码仓库
模型 / 科研
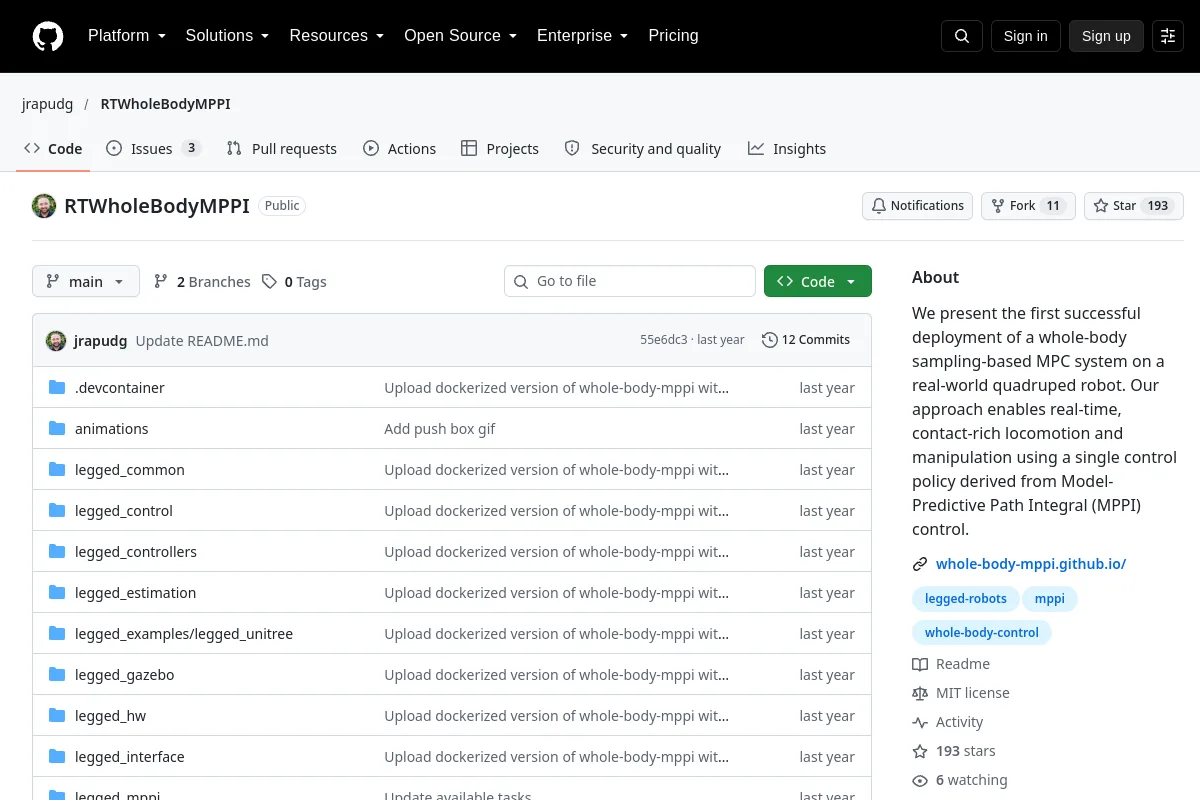
RTWholeBodyMPPI · jrapudg
我们首次在现实世界的四足机器人上成功部署基于全身采样的 MPC 系统。我们的方法可以使用……实现实时、接触丰富的运动和操纵。
概述
We present the first successful deployment of a whole-body sampling-based MPC system on a real-world quadruped robot. Our approach enables real-time, contact-rich locomotion and manipulation using…<br><br>Publisher purpose:We present the first successful deployment of a whole-body sampling-based MPC system on a real-world quadruped robot. Our approach enables real-time, contact-rich locomotion and manipulation using a single control policy derived from Model-Predictive Path Integral (MPPI) control.<br><br>Review observation/action interfaces, checkpoints, robot embodiments and adaptation requirements. Repository code licensing does not automatically license weights or training data.
项目信息
- 维护者
- jrapudg
- 主要语言
- Jupyter Notebook
- 存储库代码许可证
- MIT
- 模型重量许可证
- 未记录
- 数据集许可
- 未记录
- 硬件设计许可证
- 未记录
- 维护
- 未存档在最后记录的元数据中
- 最后观察到的存储库推送
- 2025-05-18
代码许可不会自动涵盖模型权重、数据集或硬件设计。未记录的许可证详细信息需要与发布者确认。
文档部分
- Whole-Body MPPI
- MPPI explained:
- **Release Note**
- Contents
- Installation
- MuJoCo Simulation ONLY










