 代码仓库
 科研
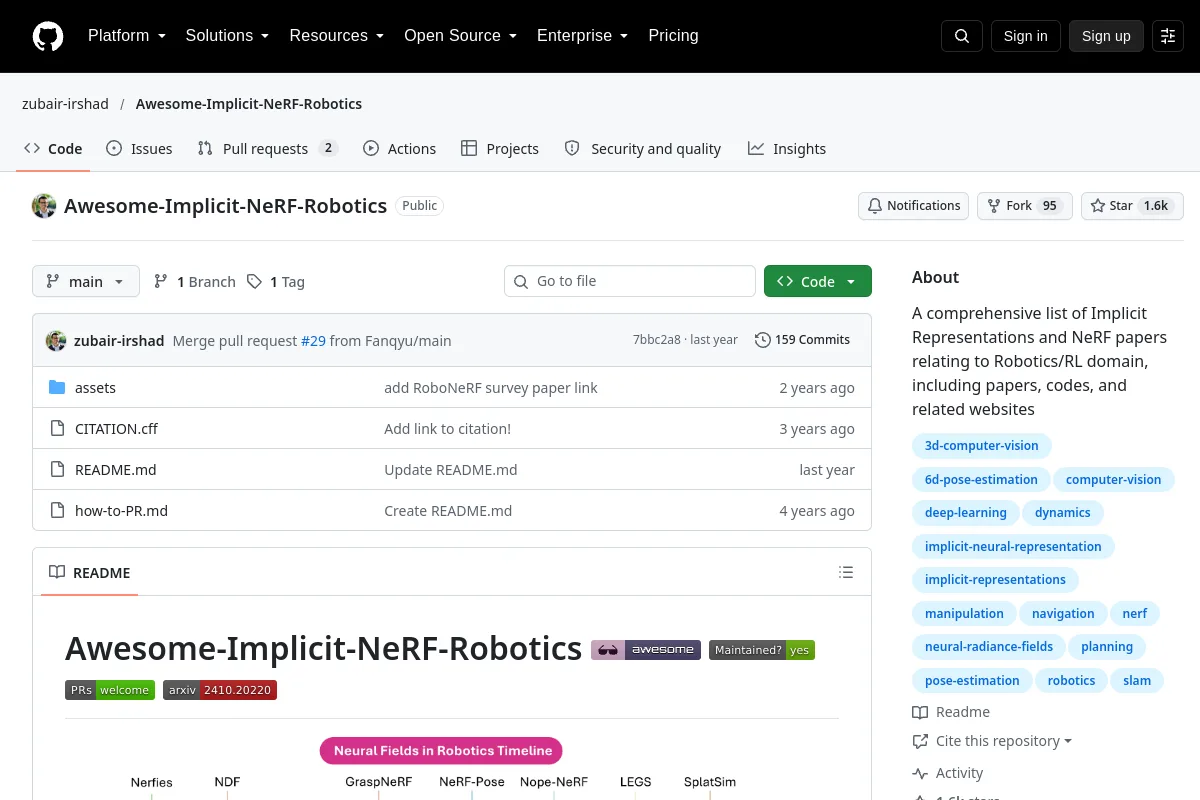
Awesome Implicit NeRF Robotics · zubair-irshad
Awesome Implicit NeRF Robotics 收集了关于机器人技术和强化学习的隐式表示和 NeRF 研究。
标准和参考集合
科研与学习 / 科研
Awesome NeRF and 3DGS SLAM 收集了 SLAM 和机器人技术的隐式表示研究。
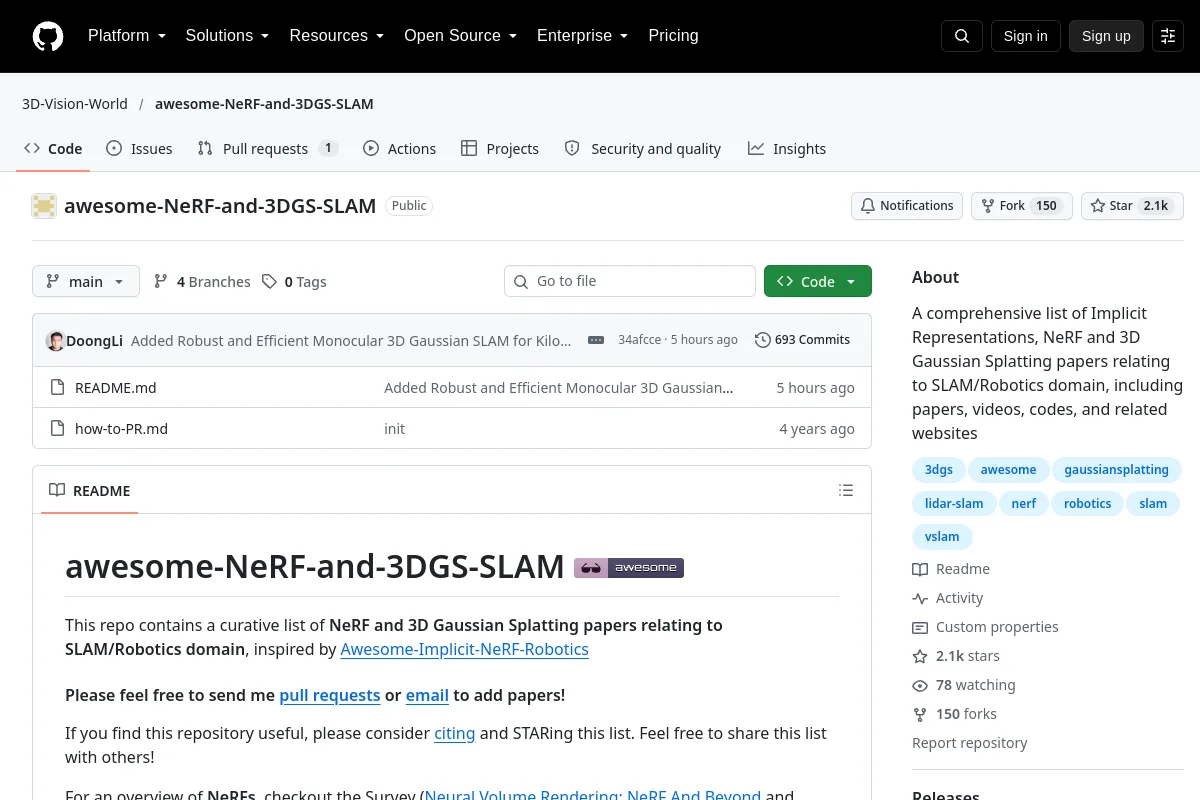
awesome NeRF and 3DGS SLAM collects implicit-representation research for SLAM and robotics.<br><br>Publisher summary:“A comprehensive list of Implicit Representations, NeRF and 3D Gaussian Splatting papers relating to SLAM/Robotics domain, including papers, videos, codes, and related websites”<br><br>Use its repository to inspect the implementation, documentation and supported workflows. This directory record identifies the maintainer, code license and related resources; it does not claim that the project has been installed or tested on your robot.
代码许可不会自动涵盖模型权重、数据集或硬件设计。未记录的许可证详细信息需要与发布者确认。
代码仓库
科研
Awesome Implicit NeRF Robotics 收集了关于机器人技术和强化学习的隐式表示和 NeRF 研究。
标准和参考集合