 代码仓库
软件工具 / 开源
Stewart-Platform · mlayek21
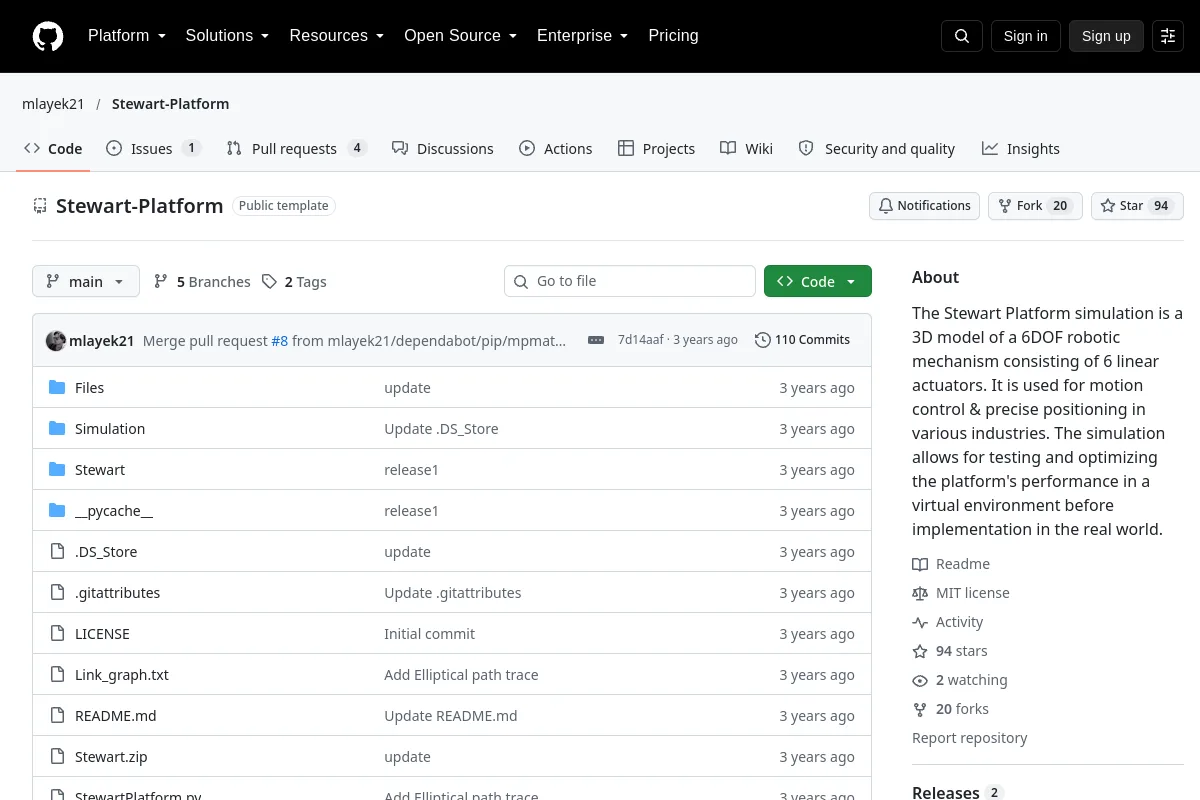
Stewart平台模拟是由6个线性致动器组成的6DOF机器人机构的3D模型。用于各行业的运动控制和精确定位。该…
概述
The Stewart Platform simulation is a 3D model of a 6DOF robotic mechanism consisting of 6 linear actuators. It is used for motion control & precise positioning in various industries. The…<br><br>Publisher purpose:The Stewart Platform simulation is a 3D model of a 6DOF robotic mechanism consisting of 6 linear actuators. It is used for motion control & precise positioning in various industries. The simulation allows for testing and optimizing the platform's performance in a virtual environment before implementation in the real world.<br><br>Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
项目信息
- 维护者
- mlayek21
- 主要语言
- Python
- 存储库代码许可证
- MIT
- 模型重量许可证
- 未记录
- 数据集许可
- 未记录
- 硬件设计许可证
- 未记录
- 维护
- 未存档在最后记录的元数据中
- 最后观察到的存储库推送
- 2023-08-29
代码许可不会自动涵盖模型权重、数据集或硬件设计。未记录的许可证详细信息需要与发布者确认。
文档部分
- 概述
- Model Details
- URDF Details
- Inverse Kinematics of Stewart Platform
- Base and Platform Anchors
- Positioning Oneself at Home










