A1
Reference catalog identity
Unitree · Application awaiting verification · Humanoid
Official identity
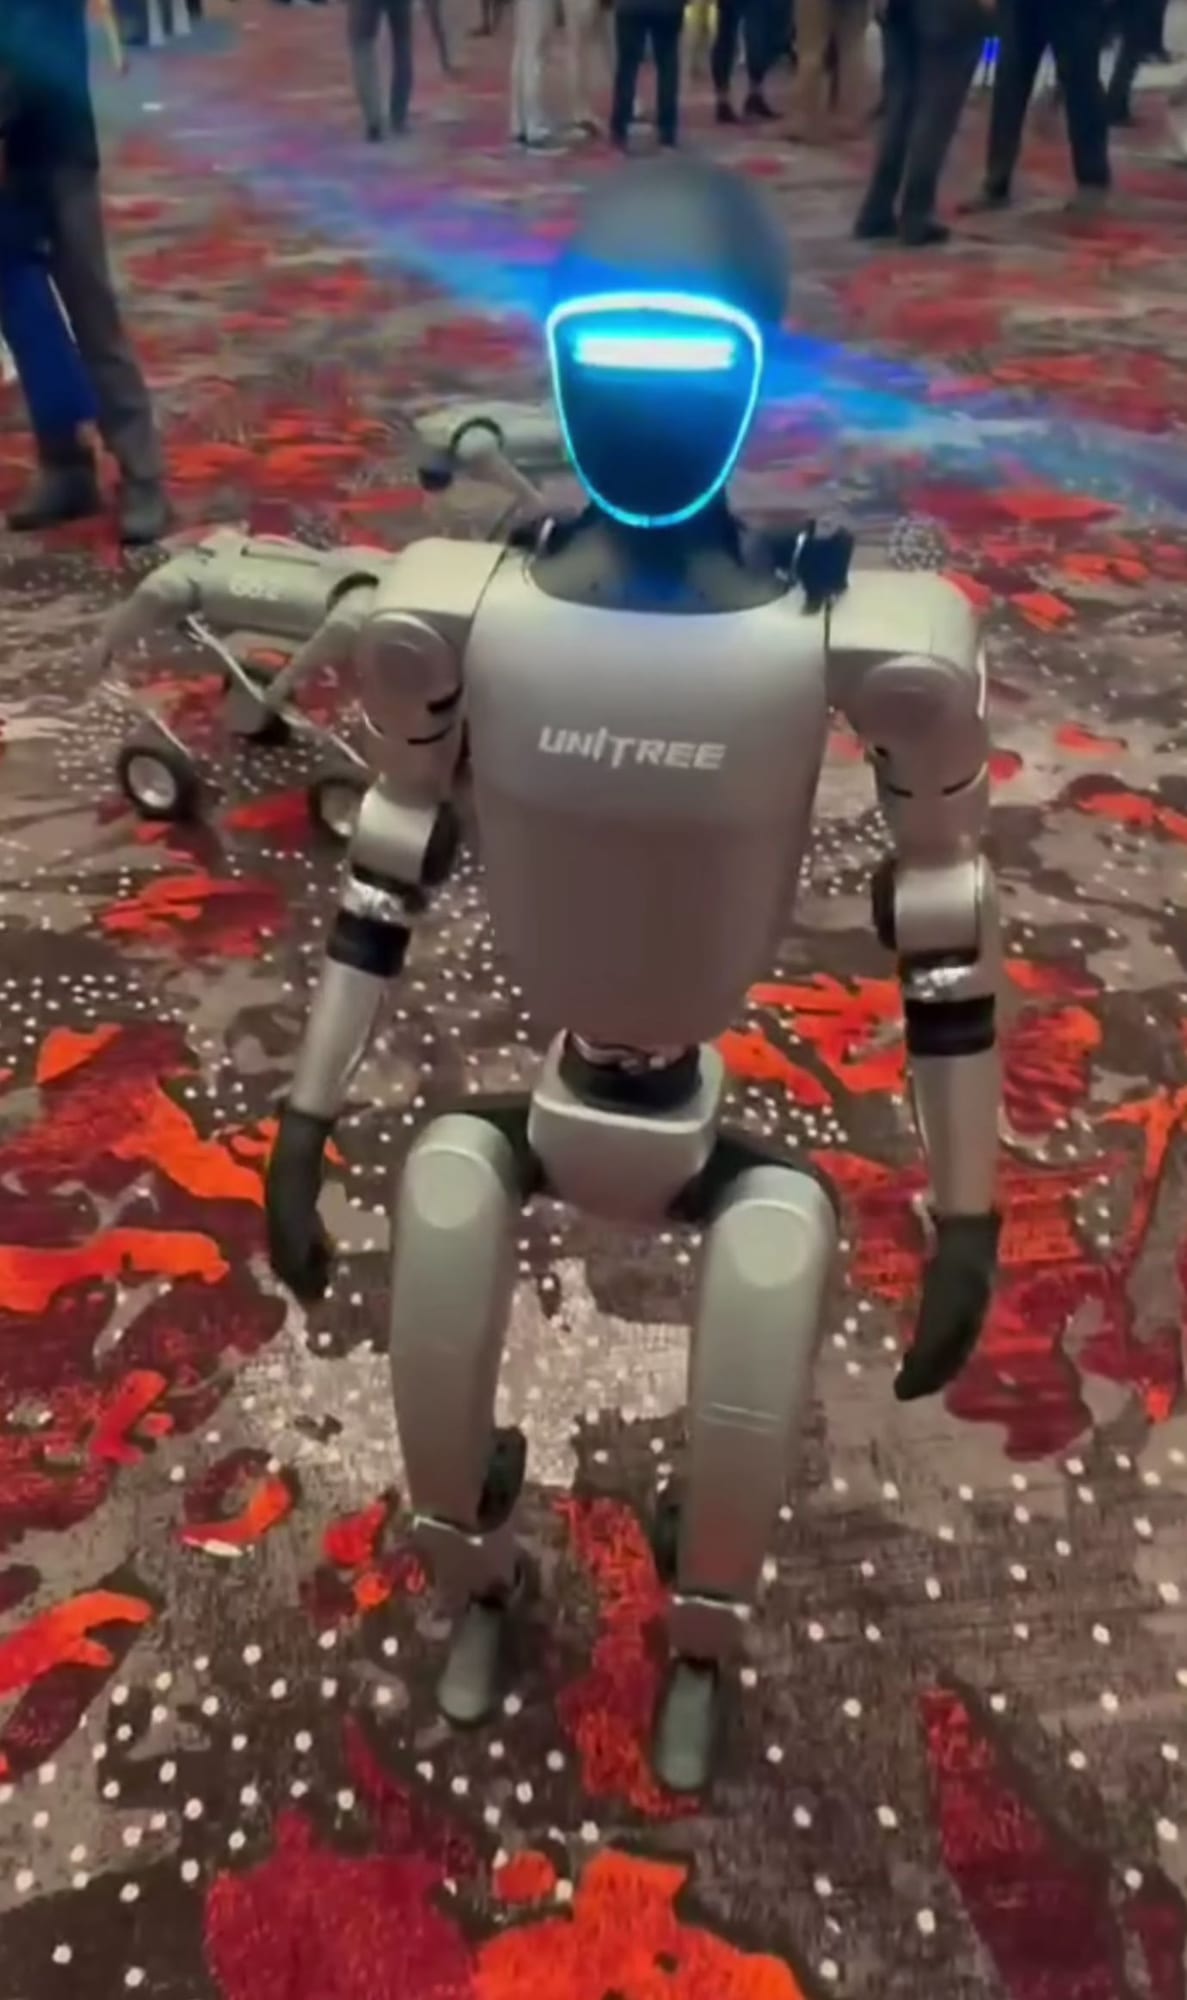
Reference photograph of the model; exact hardware edition and supplied options are unverified. · Photo source
Availability awaiting verification · Checked 2026-11-22
34 / 44 parameter fields backed by recorded evidence
Highlights refer only to the selected edition. Read measurement conditions and sources before comparing.
Officially documented robot platform. Select a configuration to inspect sourced specifications.
Compare exact editions; model names alone do not establish compatibility.
| Configuration | Key parameters | Development support | Recorded price | Verification and actions |
|---|---|---|---|---|
| G1 Availability awaiting verification 2026-11-22 | Runtime About 2 h Payload About 2 kg Weight About 35 kg Height 1320 mm | SDK: Secondary development not included MuJoCo support: Official G1 URDF and MJCF model assets | USD 13.500,00 | 32 / 44 documented fields Full edition specifications → |
| G1 EDU Availability awaiting verification 2026-11-22 | Runtime About 2 h Payload About 3 kg Weight About 35+ kg Height 1320 mm | SDK: Secondary development available MuJoCo support: Official G1 URDF and MJCF model assets ROS support: Official ROS 2 G1 low-level example Isaac Sim support: Isaac Lab environment for G1-29dof | Quotation required | 34 / 44 documented fields Full edition specifications → |
34 / 44 fields checked within the recorded source scope
This is a documentation checklist, not a performance score. Missing values are not zero, and support is not implied.
| Parameter | Value and conditions | Source and verification |
|---|---|---|
| Overall dimensions | 1320 × 450 × 200 mm | G1 EDU · official technical specification |
| Folded dimensions | 690 × 450 × 300 mm | G1 EDU · official technical specification |
| Height | 1320 mm | G1 Parameter · standing dimensions |
| Weight | About 35+ kg | G1 Parameter · weight |
| Degrees of freedom | 23–43 | G1 Parameter · total degrees of freedom |
| Degrees of freedom per leg | 6 | G1 EDU · official technical specification |
| Waist degrees of freedom | 1 + 2 optional | G1 EDU · official technical specification |
| Degrees of freedom per arm | 5 | G1 EDU · official technical specification |
| Degrees of freedom per hand | 7 + 2 optional wrist joints | G1 EDU · official technical specification |
| Thigh and calf length | 0.6 m | G1 EDU · official technical specification |
| Published arm span | About 0.45 m | G1 EDU · official technical specification |
| Payload | About 3 kg | G1 Parameter · Arm Maximum Load |
| Speed | Not yet verified | No sourced value recorded for this edition. |
| Joint ranges and speeds | Waist Z ±155°; knee 0–165°; hip P ±154°, R −30–170°, Y ±158°; waist X/Y ±30°; wrist P/Y ±92.5° | G1 EDU · official technical specification |
| Joint torque | 120 N·m | G1 EDU · official technical specification |
| Joint motor type | Low-inertia high-speed internal-rotor PMSM | G1 EDU · official technical specification |
| Joint output bearings | Industrial crossed-roller bearings | G1 EDU · official technical specification |
| Joint encoders | Dual encoders | G1 EDU · official technical specification |
| End-effector and tool interface | Optional Dex3-1 three-finger hand; optional tactile arrays; optional wrist joints | G1 EDU · official technical specification |
| Terrain and obstacle limits | Not yet verified | No sourced value recorded for this edition. |
| Parameter | Value and conditions | Source and verification |
|---|---|---|
| Power supply and consumption | 13-series lithium battery | G1 EDU · official technical specification |
| Battery | 9000 mAh | G1 EDU · official technical specification |
| Runtime | About 2 h | G1 EDU · official technical specification |
| Charging and battery replacement | 54 V, 5 A charger | G1 EDU · official technical specification |
| Charging time | Not yet verified | No sourced value recorded for this edition. |
| Cooling system | Local air cooling | G1 EDU · official technical specification |
| IP rating | Not yet verified | No sourced value recorded for this edition. |
| Operating temperature | Not yet verified | No sourced value recorded for this edition. |
| Parameter | Value and conditions | Source and verification |
|---|---|---|
| Perception and sensors | Depth camera and 3D LiDAR; four-microphone array | G1 EDU · official technical specification |
| Audio input and output | 4-microphone array; 5 W speaker | G1 EDU · official technical specification |
| Onboard computing | 8-core CPU; optional additional computing module | G1 EDU · official technical specification |
| I/O and communication interfaces | Wi-Fi 6; Bluetooth 5.2 | G1 EDU · official technical specification |
| Joint electrical routing | Hollow electrical routing through all joints | G1 EDU · official technical specification |
| Software and operating system | Not yet verified | No sourced value recorded for this edition. |
| Software update mechanism | OTA software updates | G1 EDU · official technical specification |
| SDK | Secondary development available | G1 EDU · official technical specification |
| ROS support | Official ROS 2 G1 low-level example | Section 3 · g1/lowlevel/g1_low_level_example |
| Isaac Sim support | Isaac Lab environment for G1-29dof | Supported robots; G1-29dof training and sim-to-sim examples |
| MuJoCo support | Official G1 URDF and MJCF model assets | Overview; MuJoCo visualization; per-variant model table |
| Software license and access | Not yet verified | No sourced value recorded for this edition. |
| Hardware requirements | Not yet verified | No sourced value recorded for this edition. |
| Parameter | Value and conditions | Source and verification |
|---|---|---|
| Documented intended use | Not yet verified | No sourced value recorded for this edition. |
| Safety functions and standards | Not yet verified | No sourced value recorded for this edition. |
| Warranty and support | 18 months | G1 EDU · official technical specification |
No verified price recorded. Request a configuration-specific quotation.
Recorded prices are dated evidence, not a live stock or delivery commitment. Check currency, taxes, accessories and integration scope with the publisher.
Photographs identify the model; they do not prove which configuration or optional equipment is supplied.
Reference facts describe a model, may combine editions and are not treated as verified hardware-configuration specifications.
Unitree G1
View the recorded source ↗Reference catalog values; edition and measurement conditions remain unverified.
Unitree G1 EDU
View the recorded source ↗Reference catalog values; edition and measurement conditions remain unverified.
Reference disagreements are research leads, not verified configuration parameters.
Unitree · Robozaps · We Build Humanoids · BotUpYourLife
| Parameter | Official record | Reference catalog differences | Editorial decision |
|---|---|---|---|
| Degrees of freedom | 23 base; 23–43 EDU, depending on options | Some catalogs show the family range; others show only 23. | Keep G1 and G1 EDU as separate configurations; do not treat the family maximum as the base specification. |
| Payload | About 2 kg base / about 3 kg EDU; posture-dependent arm maximum | Catalogs vary between a single number and a configuration-dependent description. | Retain the approximate value, arm-load scope and posture condition; do not normalize it as rated industrial payload. |
| Speed | No walking-speed value found in the reviewed public parameter table. | Robozaps reports 2 m/s from a third party; BotUpYourLife reports 6.5 km/h. | No official speed is populated from these reference values; primary evidence is still required. |
| IP rating | No IP value found in the reviewed public parameter table. | BotUpYourLife reports IP54; We Build Humanoids marks it not published. | Keep ingress protection unverified until a configuration-specific official document is located. |
| Price | Base from USD 13,500, excluding tax and shipping; EDU by quotation | Catalog ranges can combine dealers, regions and EDU options. | Show each dated quotation with currency, edition and scope; do not merge them into one model price range. |
Suggest a correction or claim manufacturer ownership · Coverage and verification